Sebastian’s Robot Zoo
See the full range of projects, from hobby projects and EU prototypes to certified products.
The Zoo
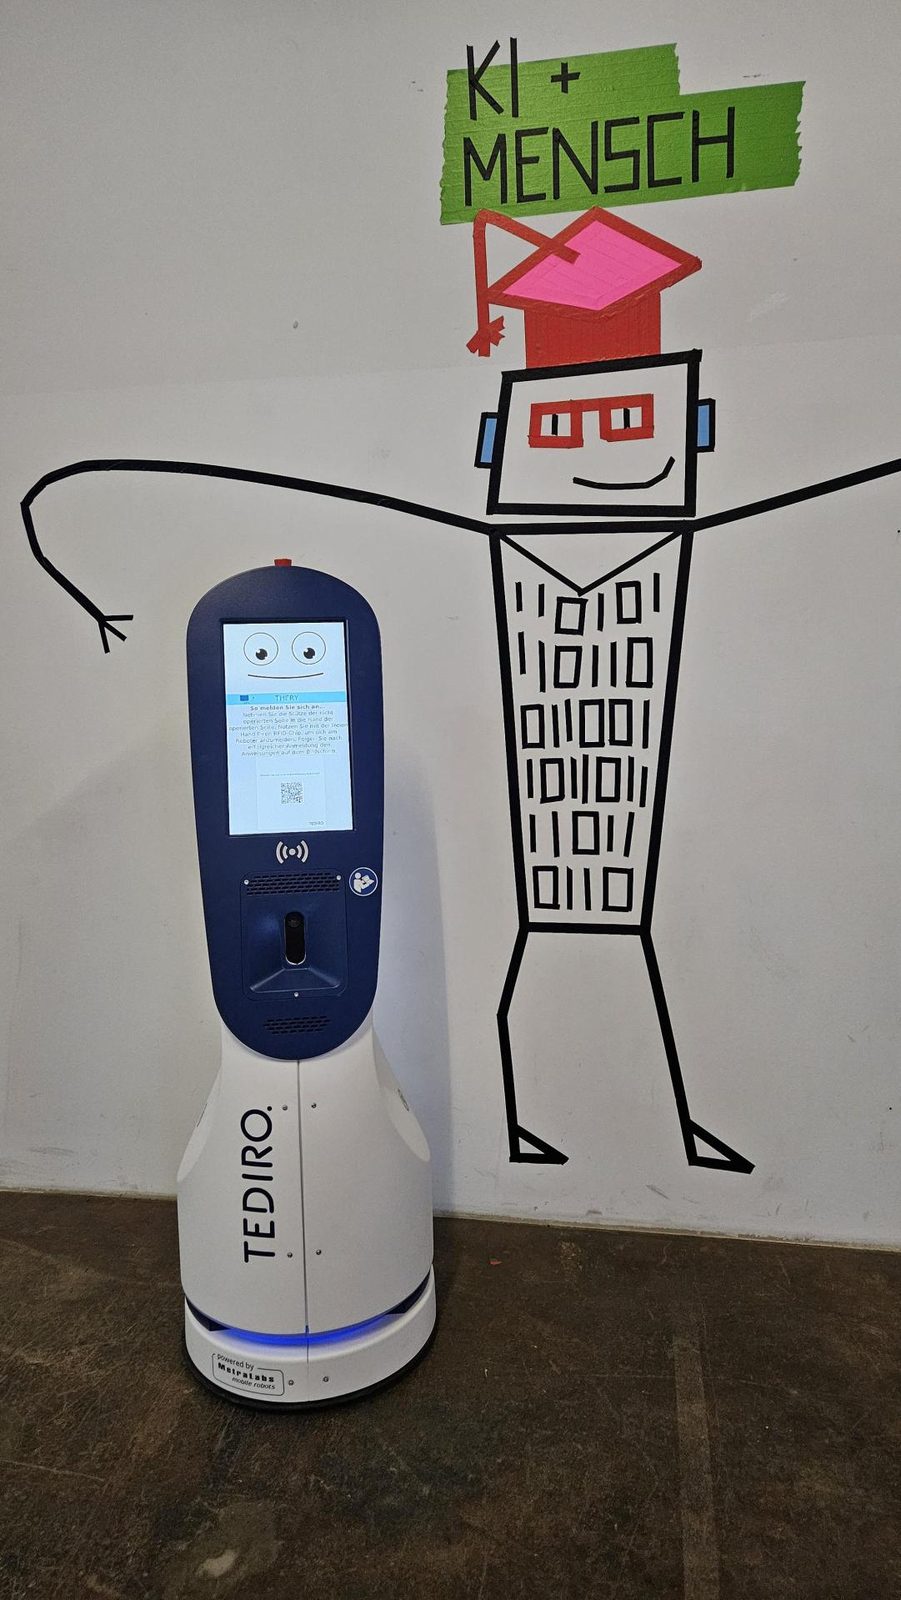
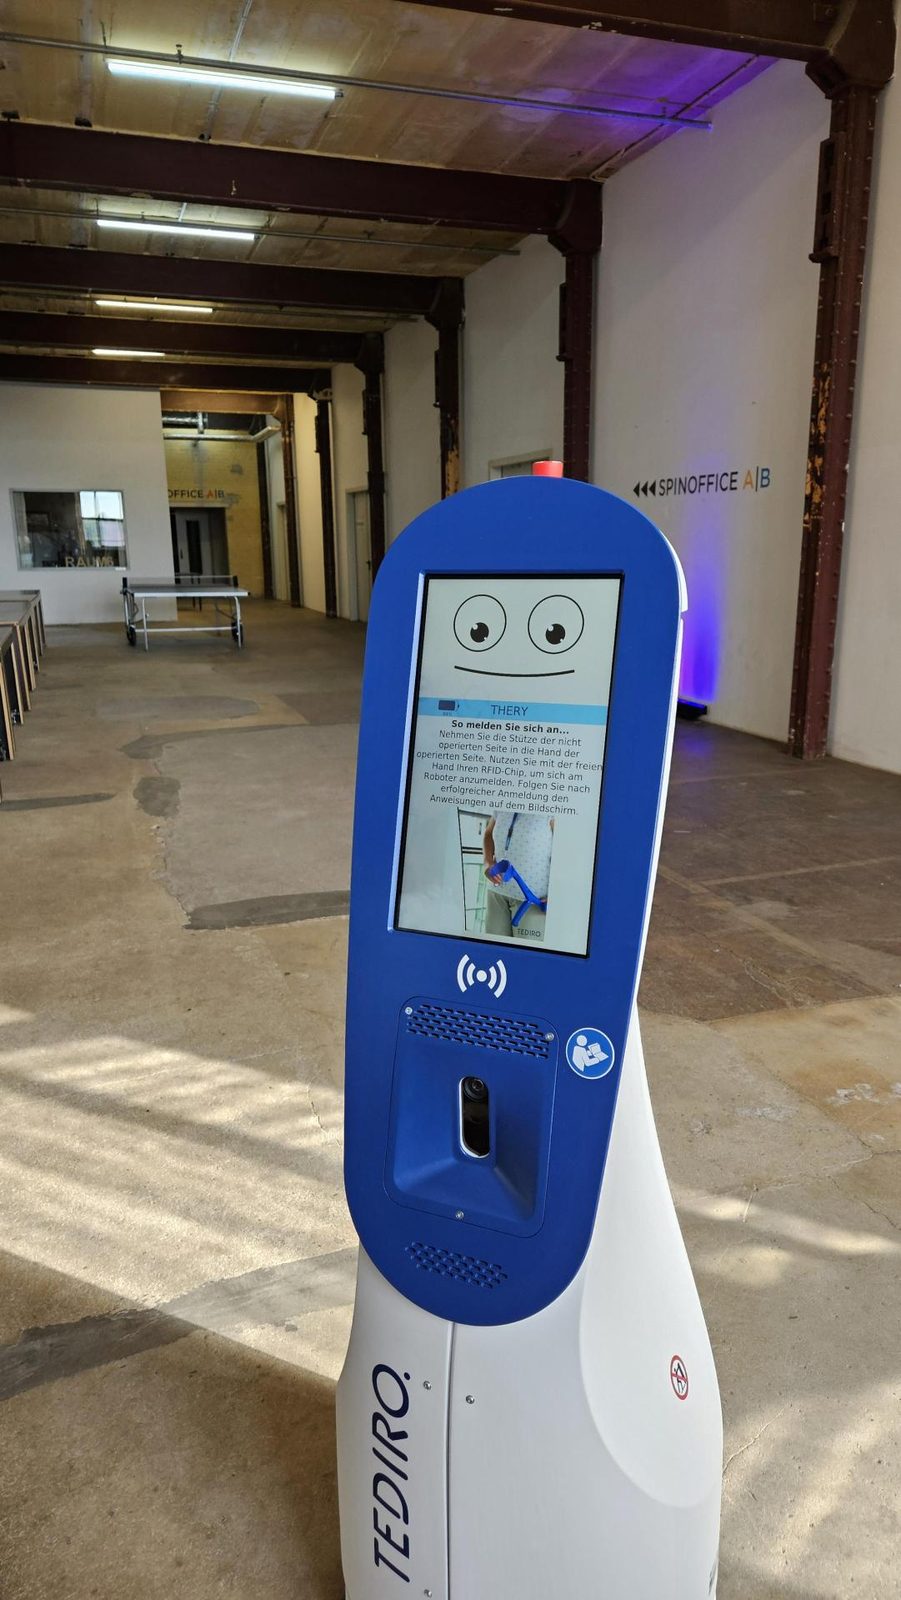
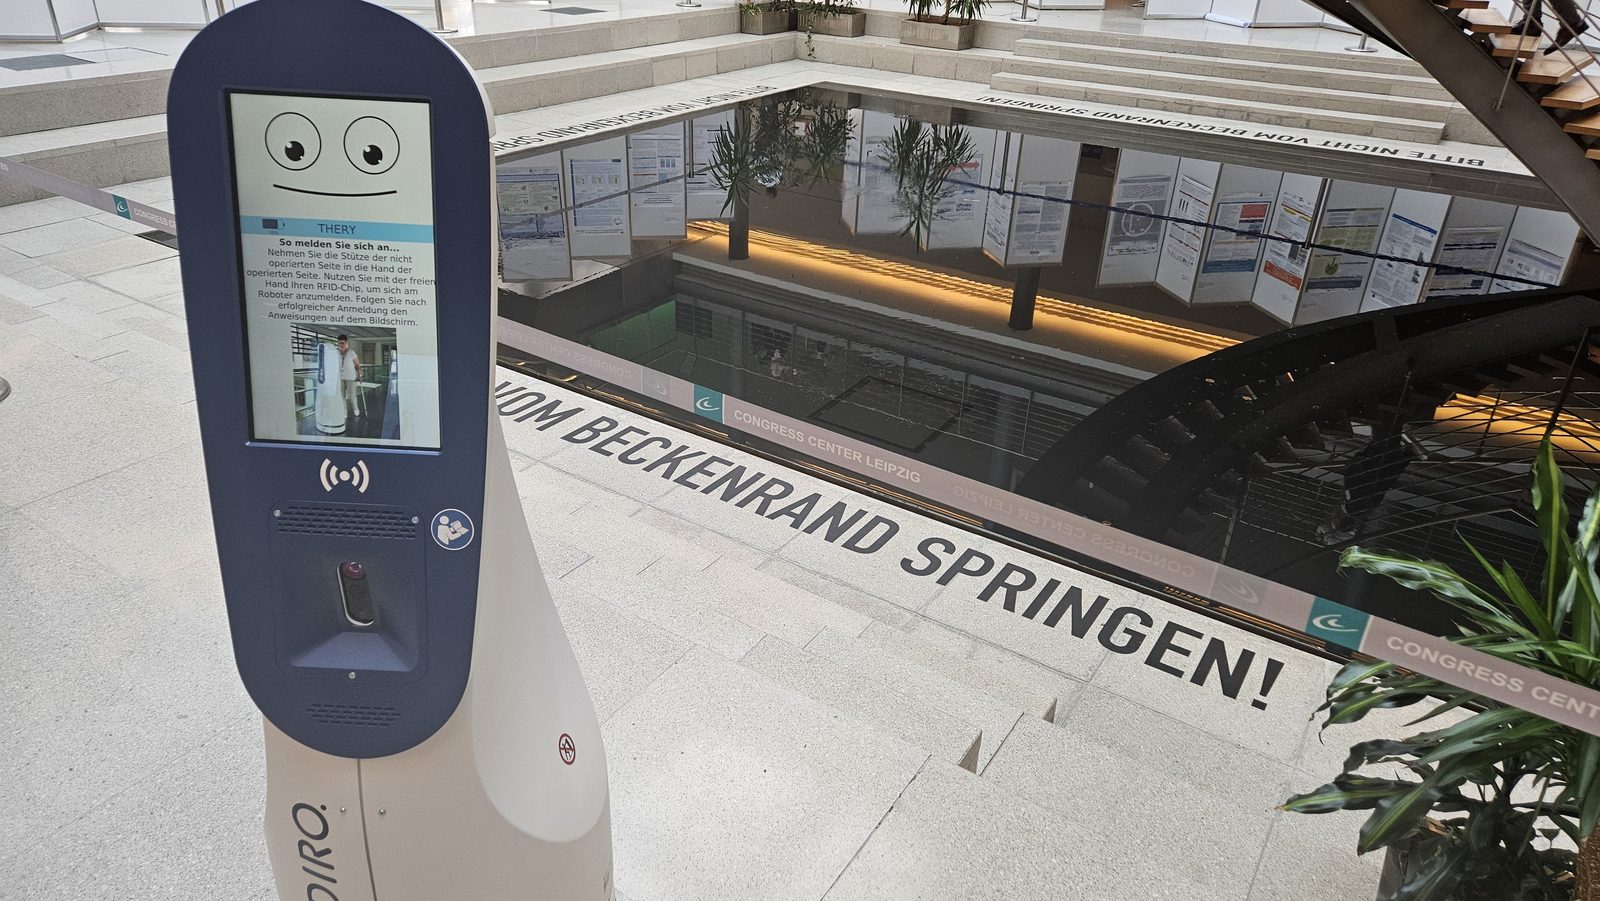
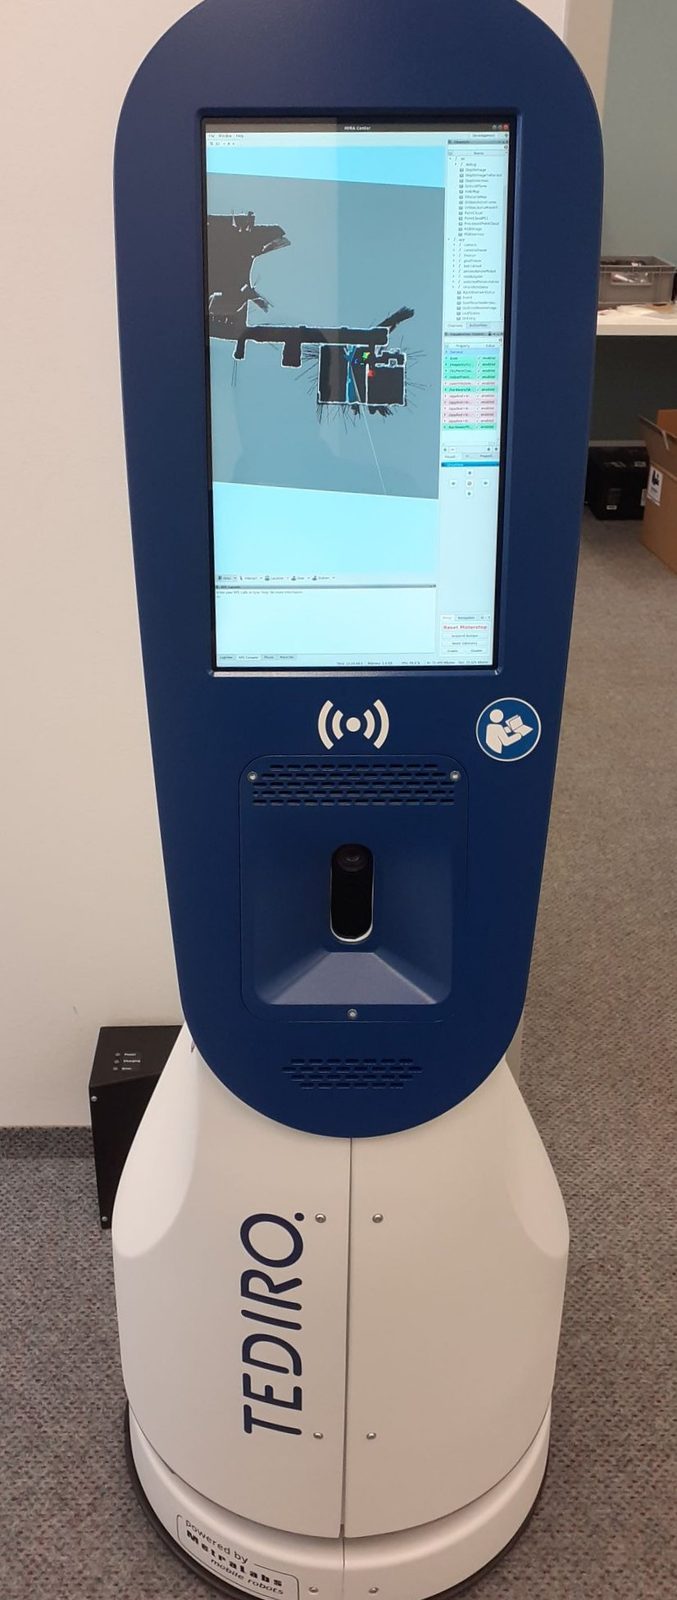
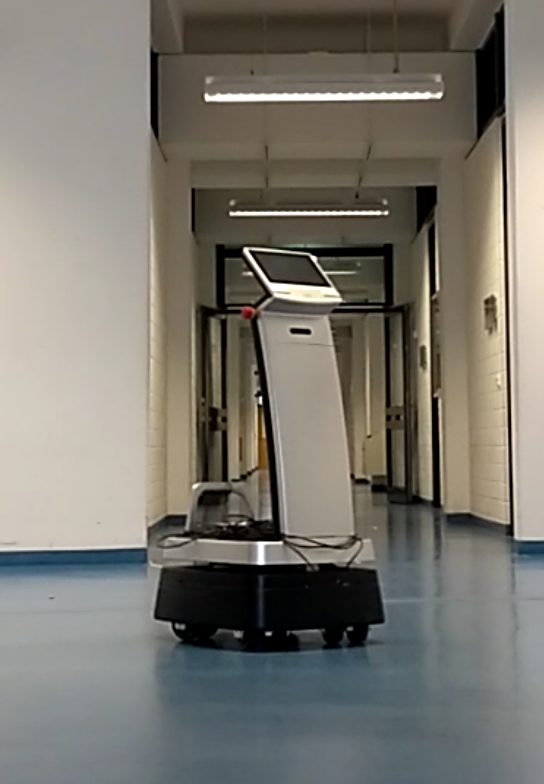
THERY
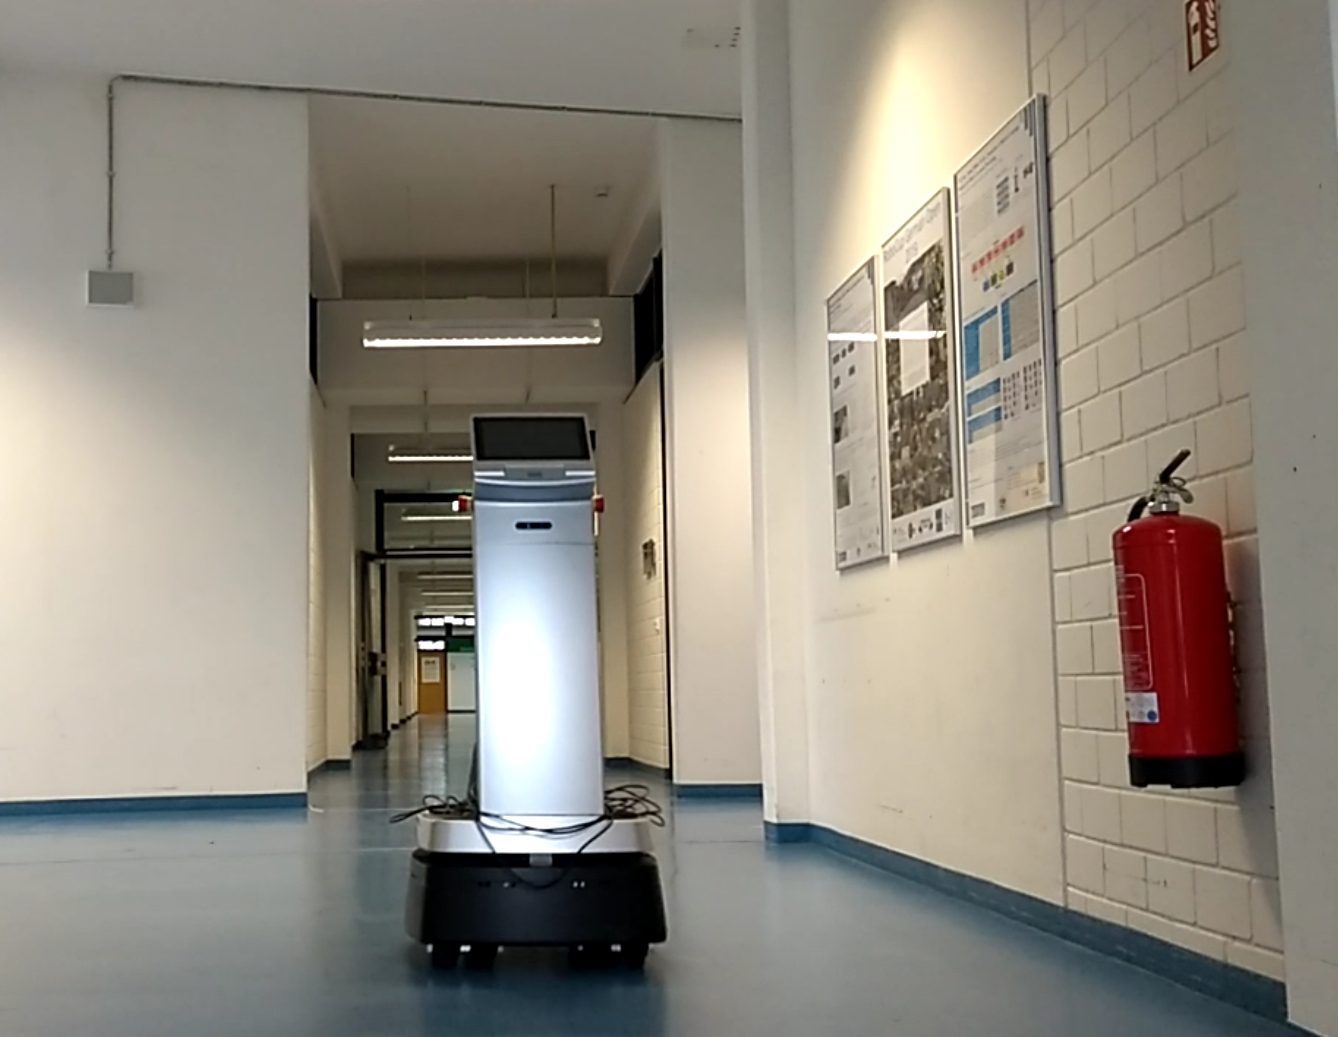
The world's first mobile robot classified as a medical device on the EU market. Used for gait rehabilitation: the robot drives in front of the patient and provides audio-visual feedback to improve the walking pattern.
Tech: 1x 2D LiDAR, RGB-D camera, depth camera, MIRA software framework
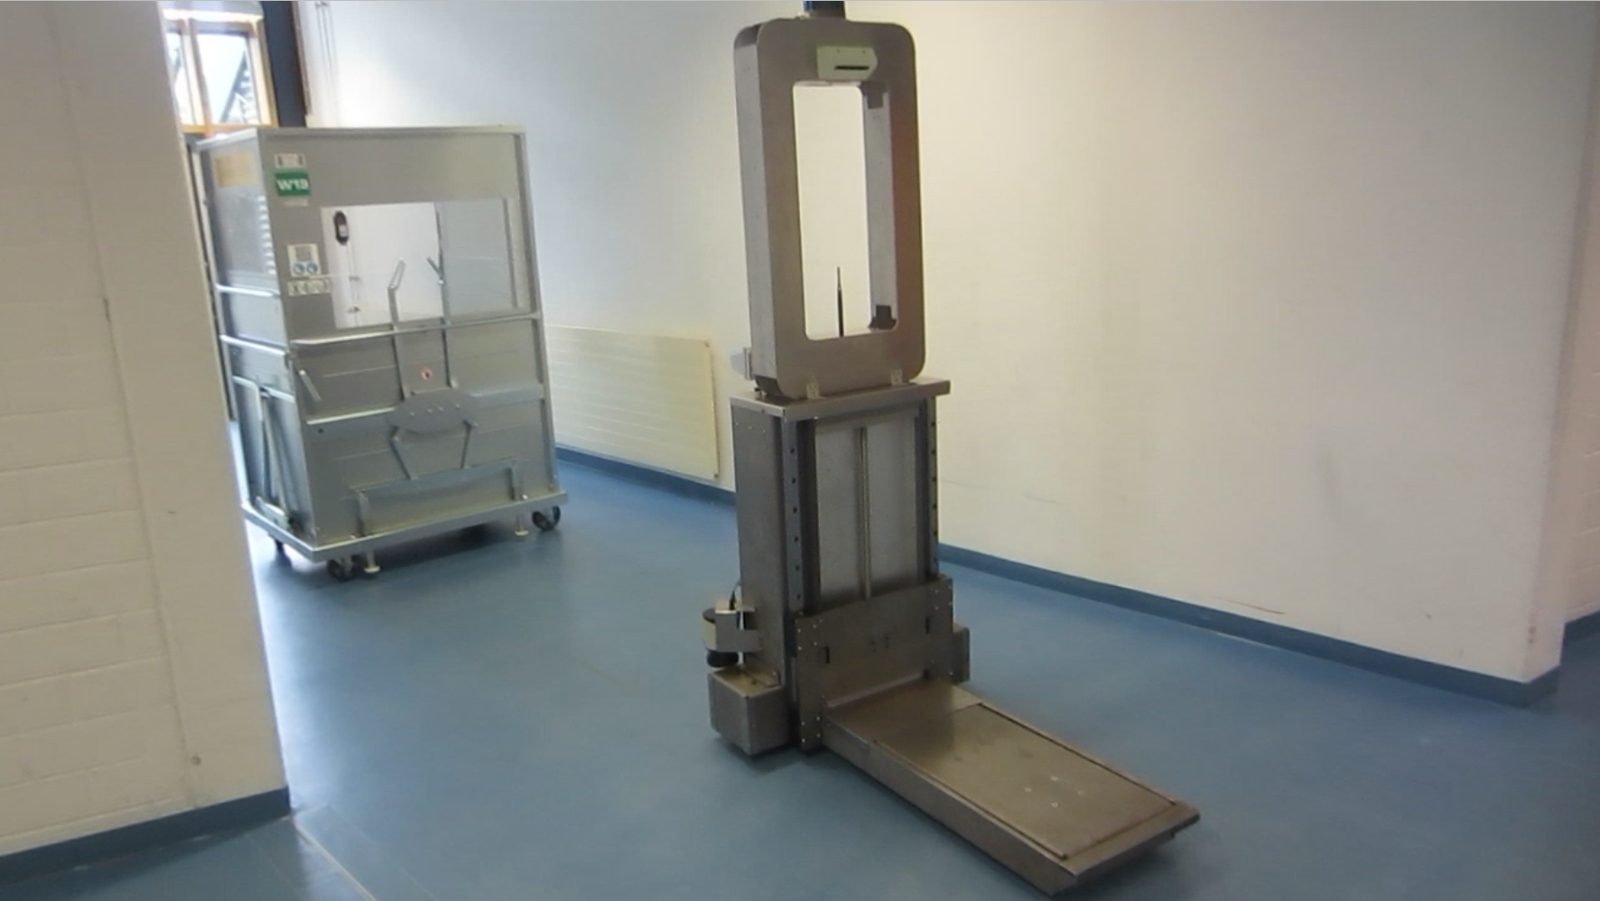
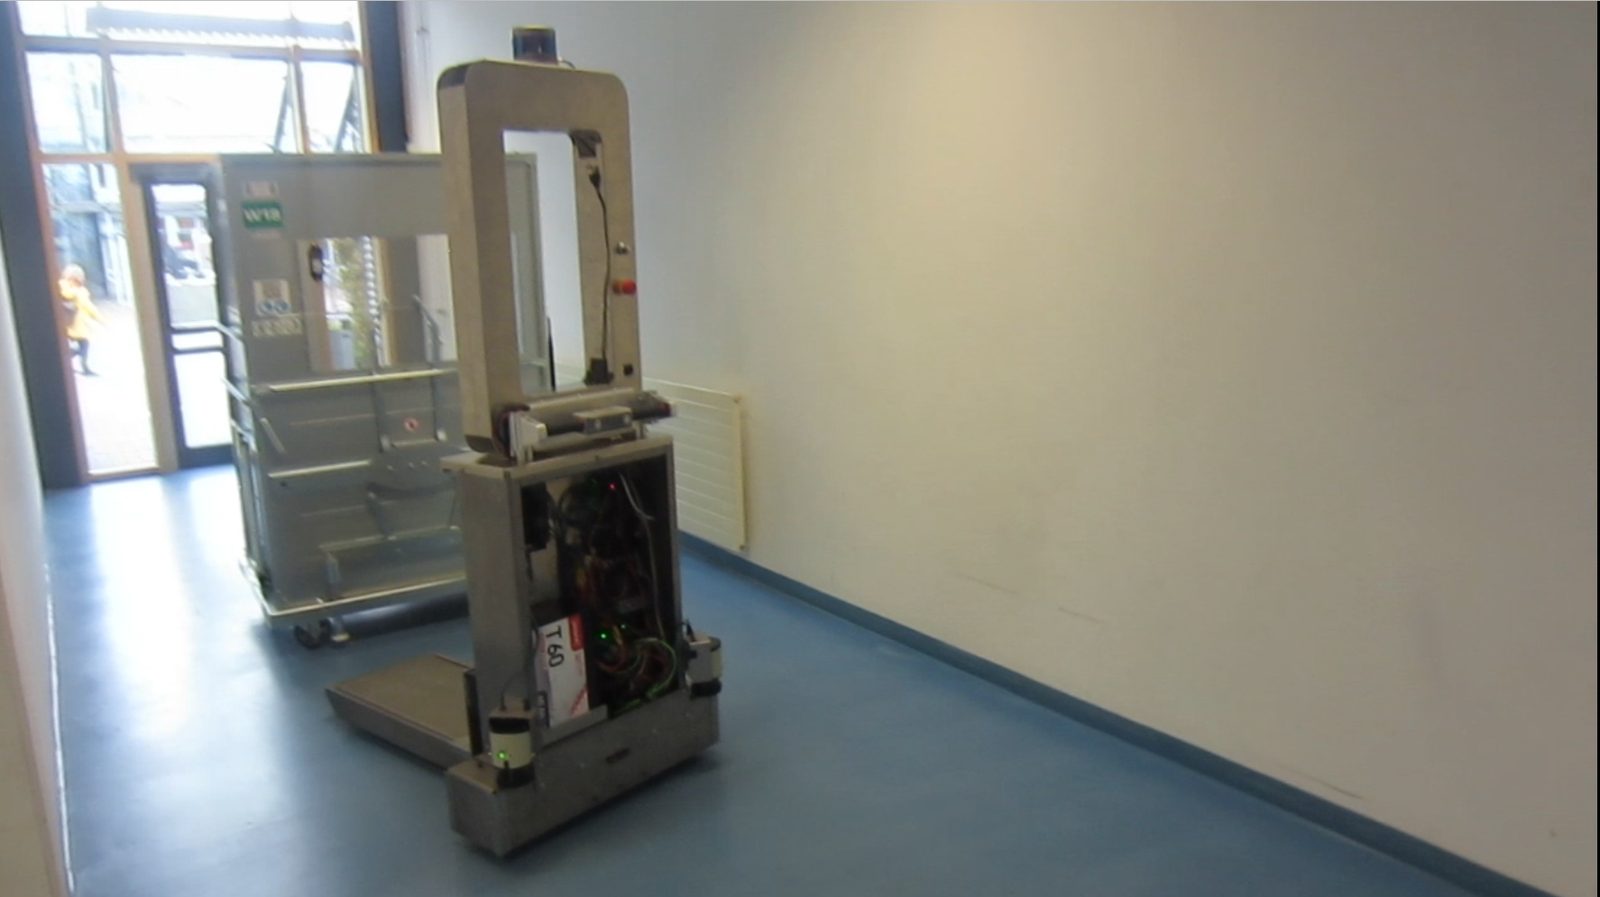
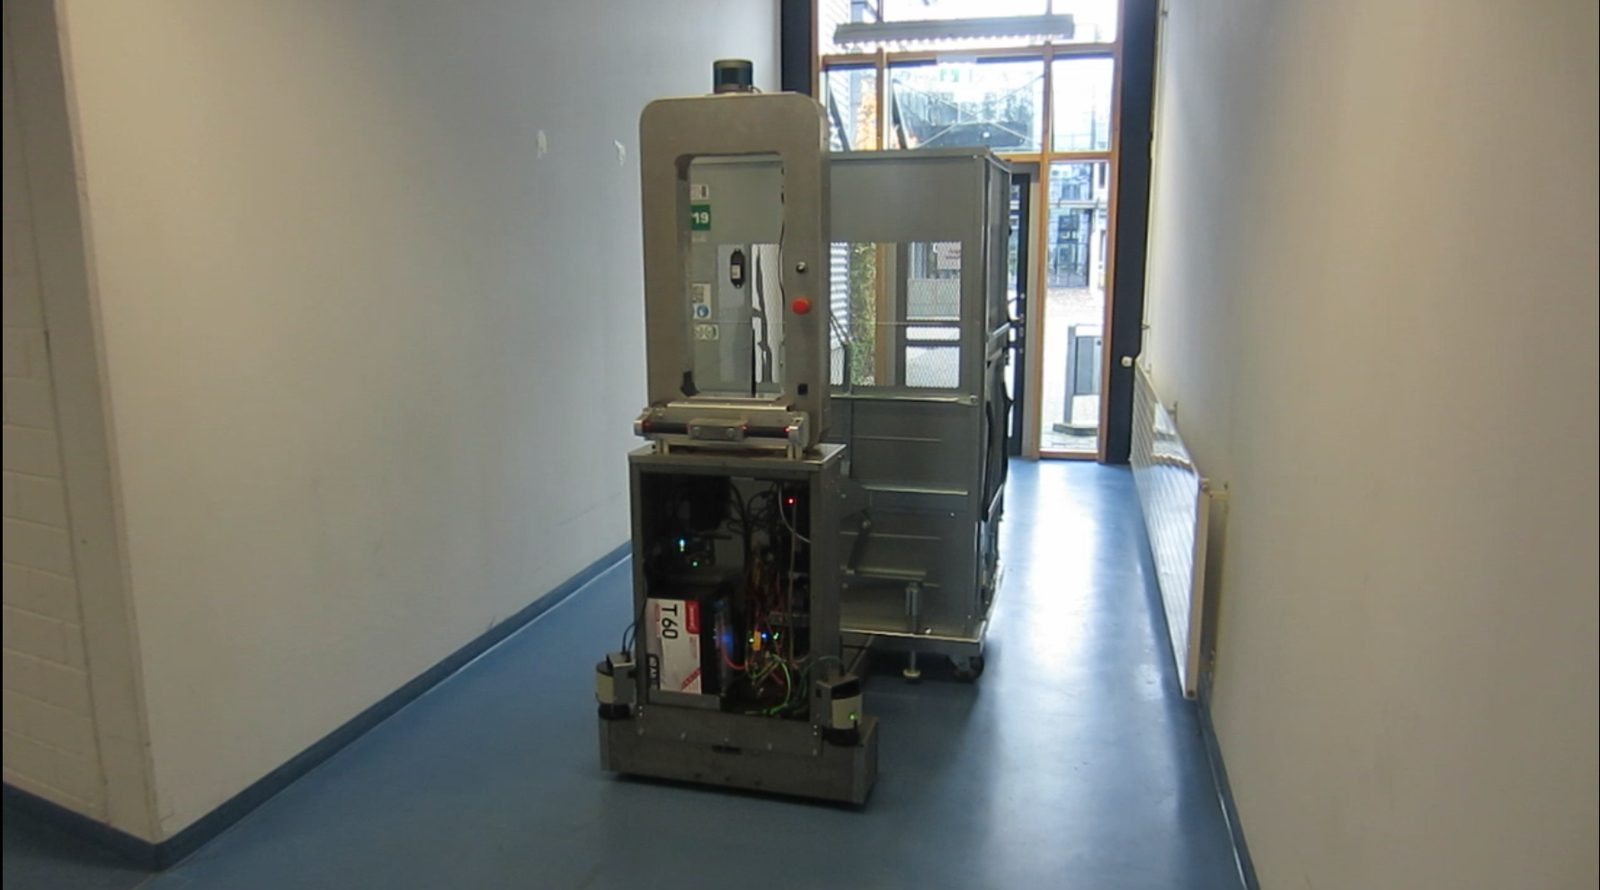
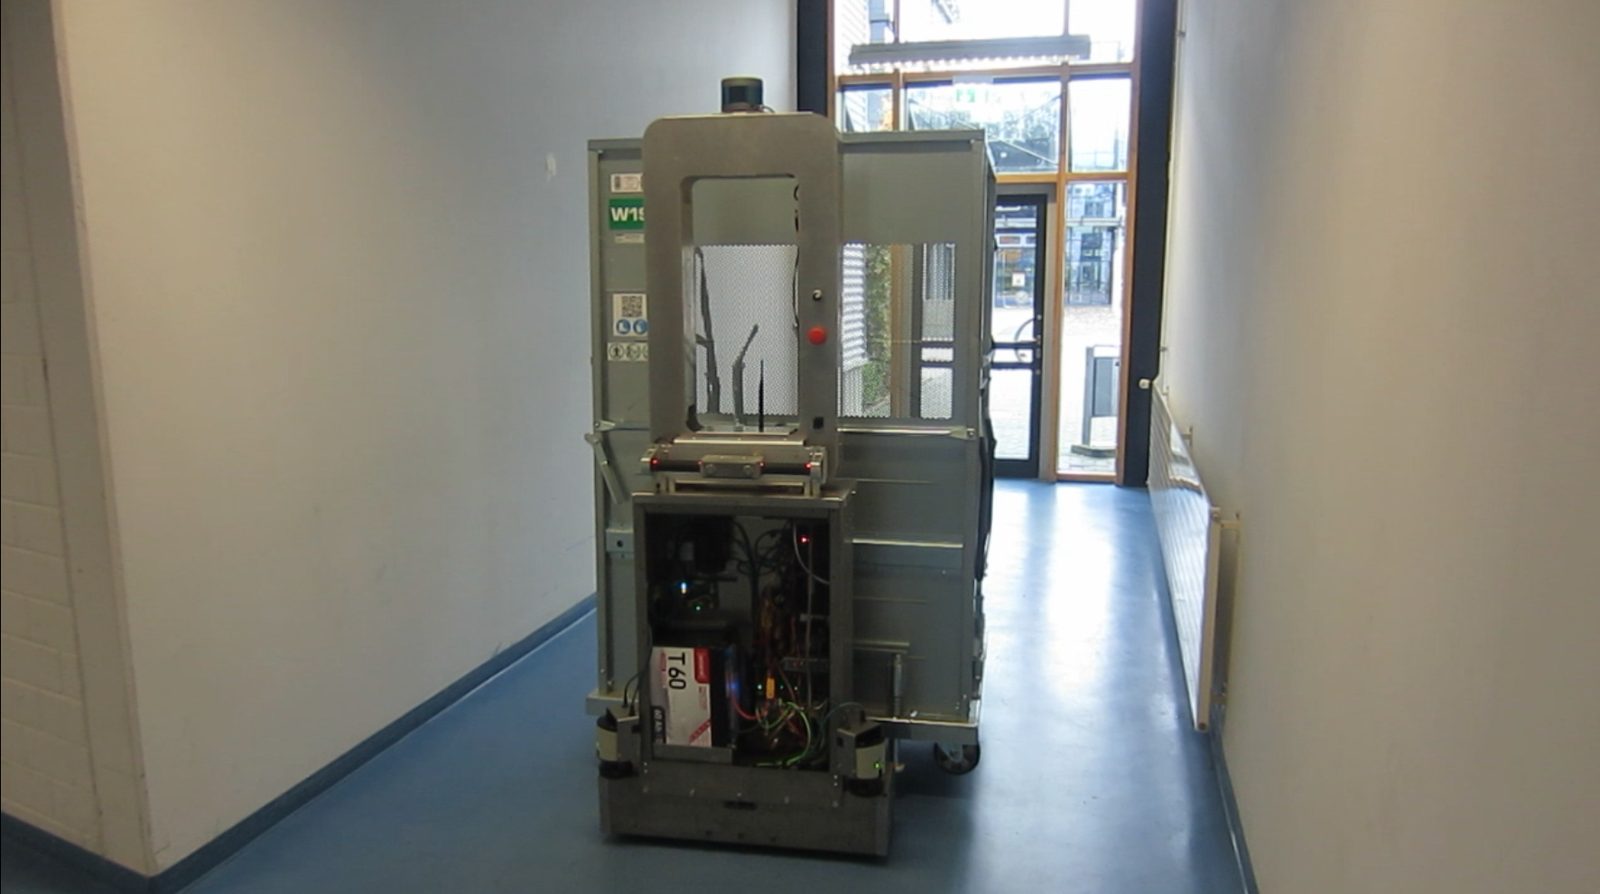
robile_1
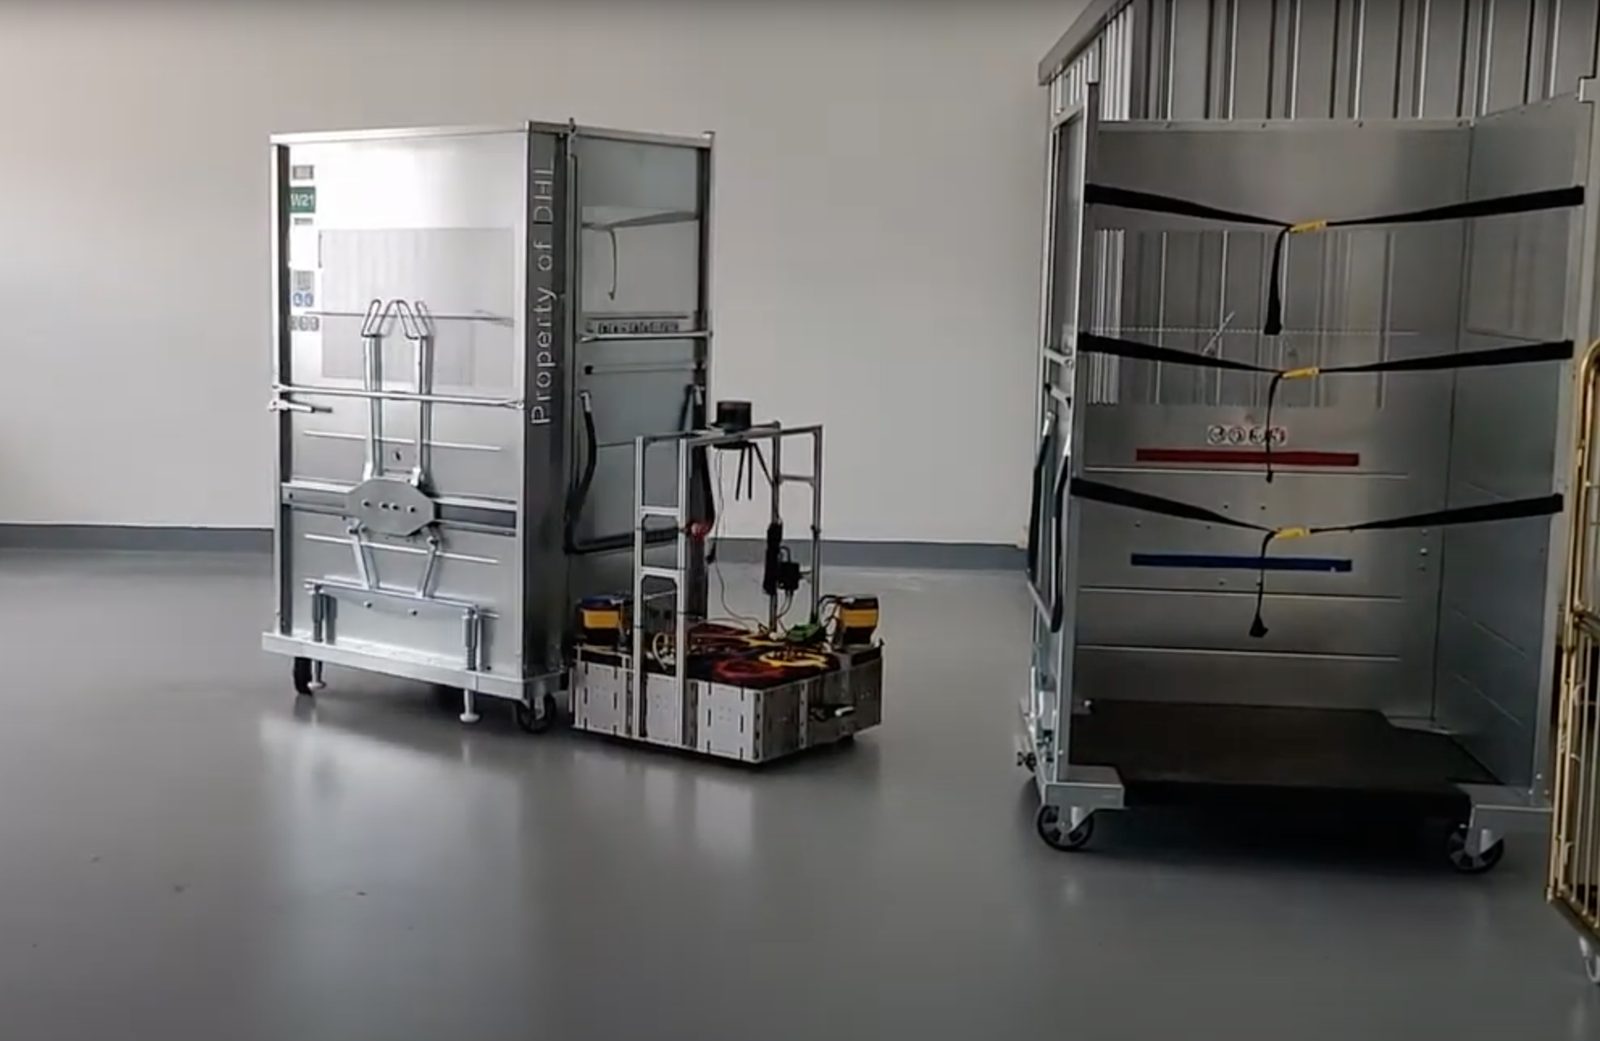
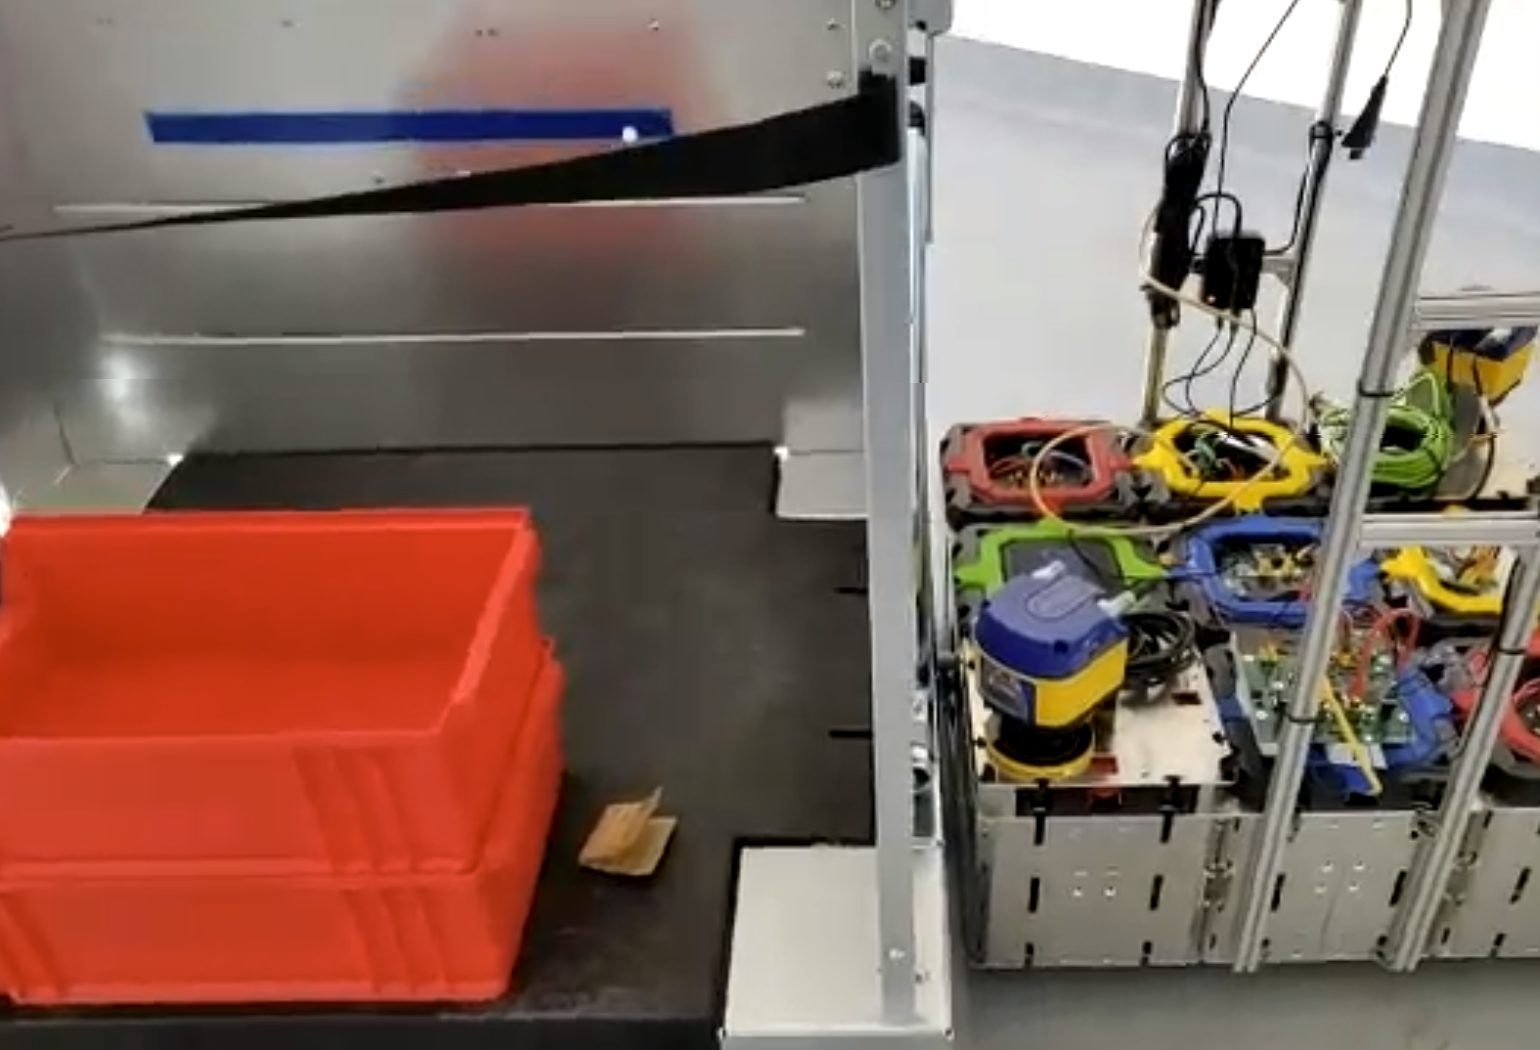
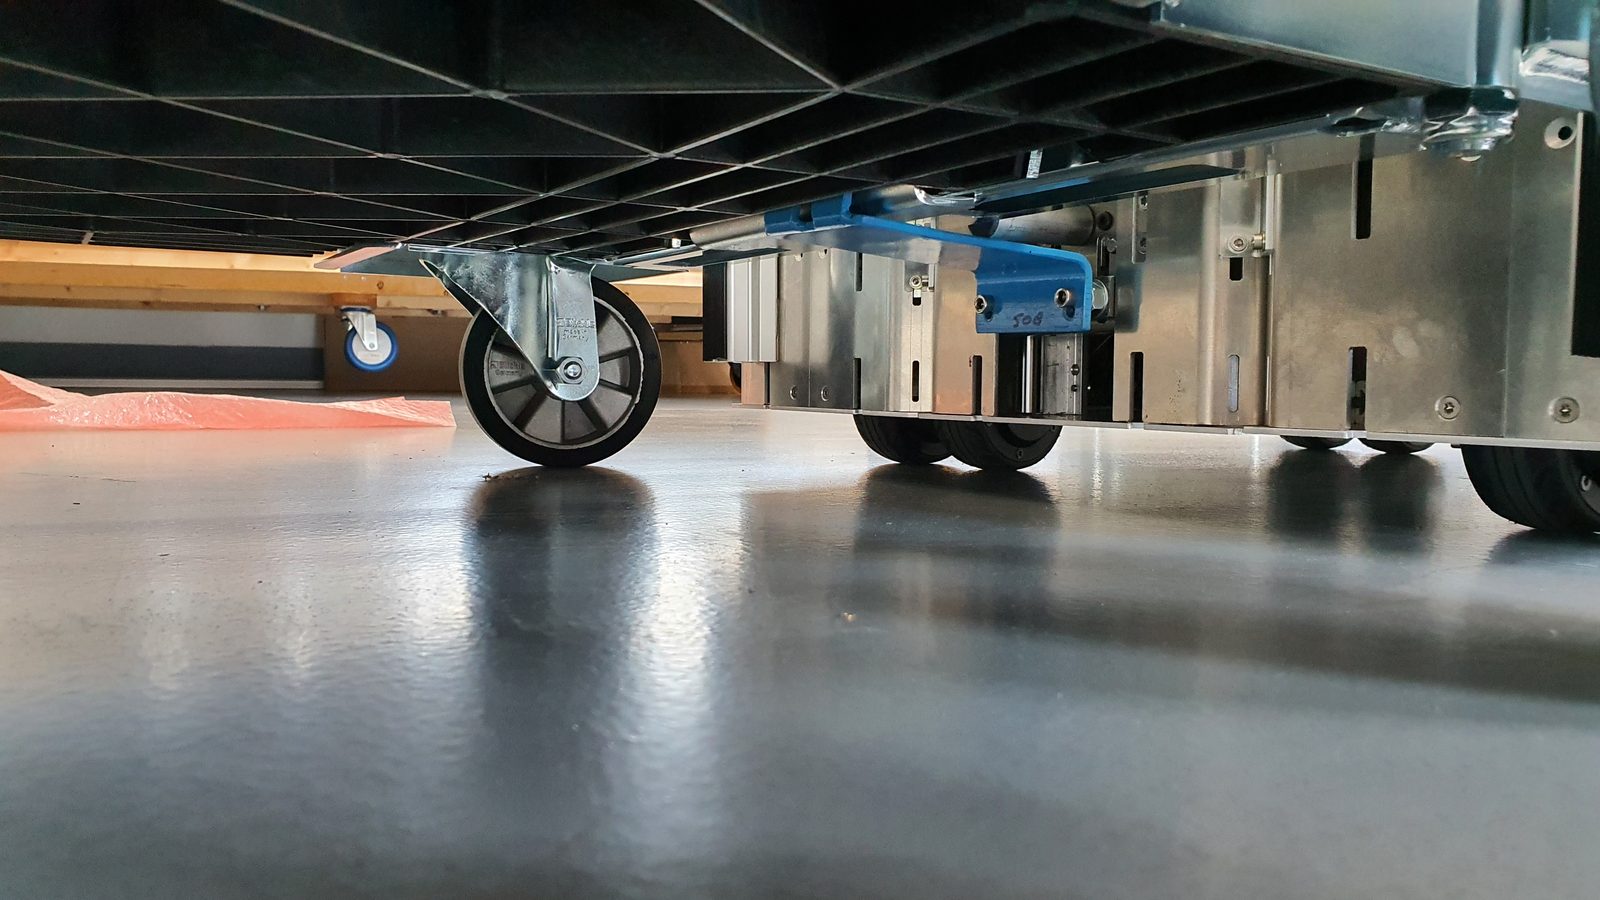
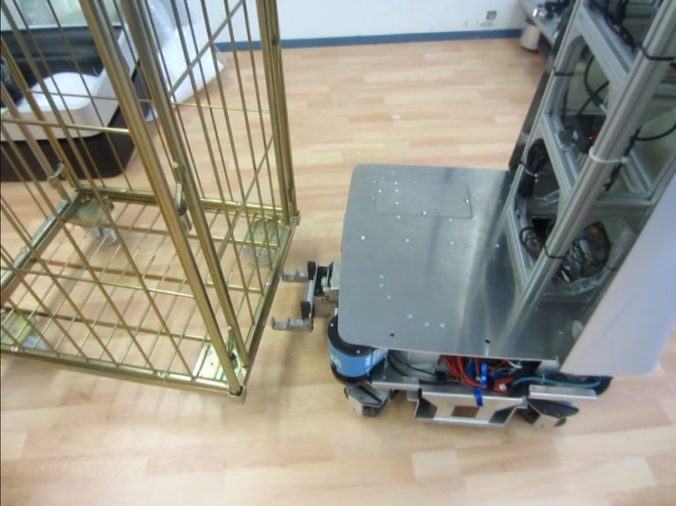
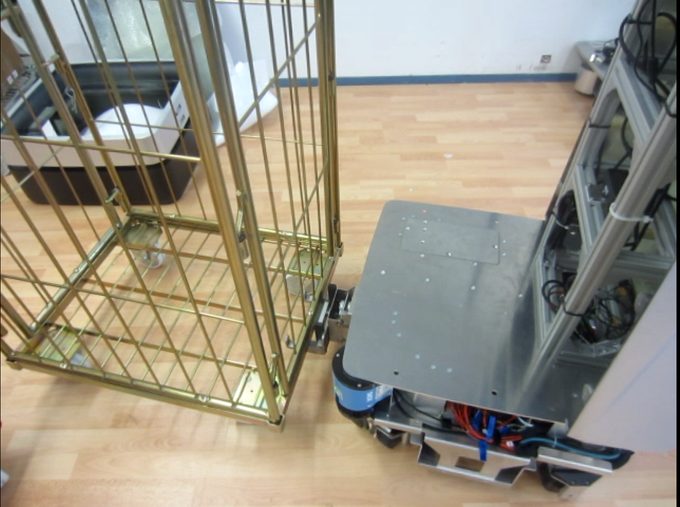
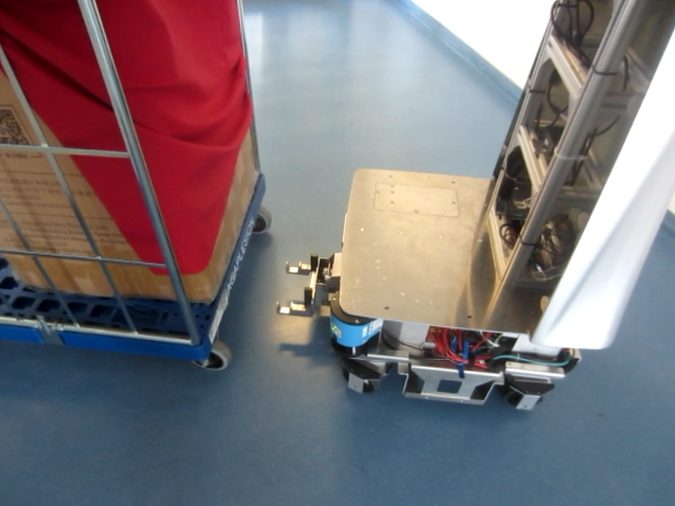
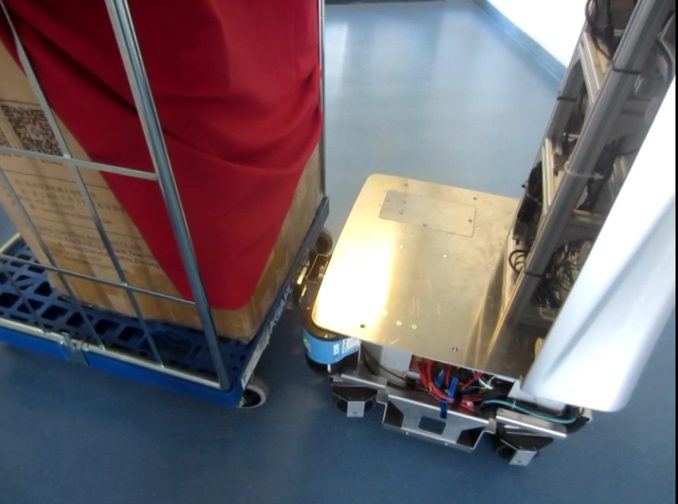
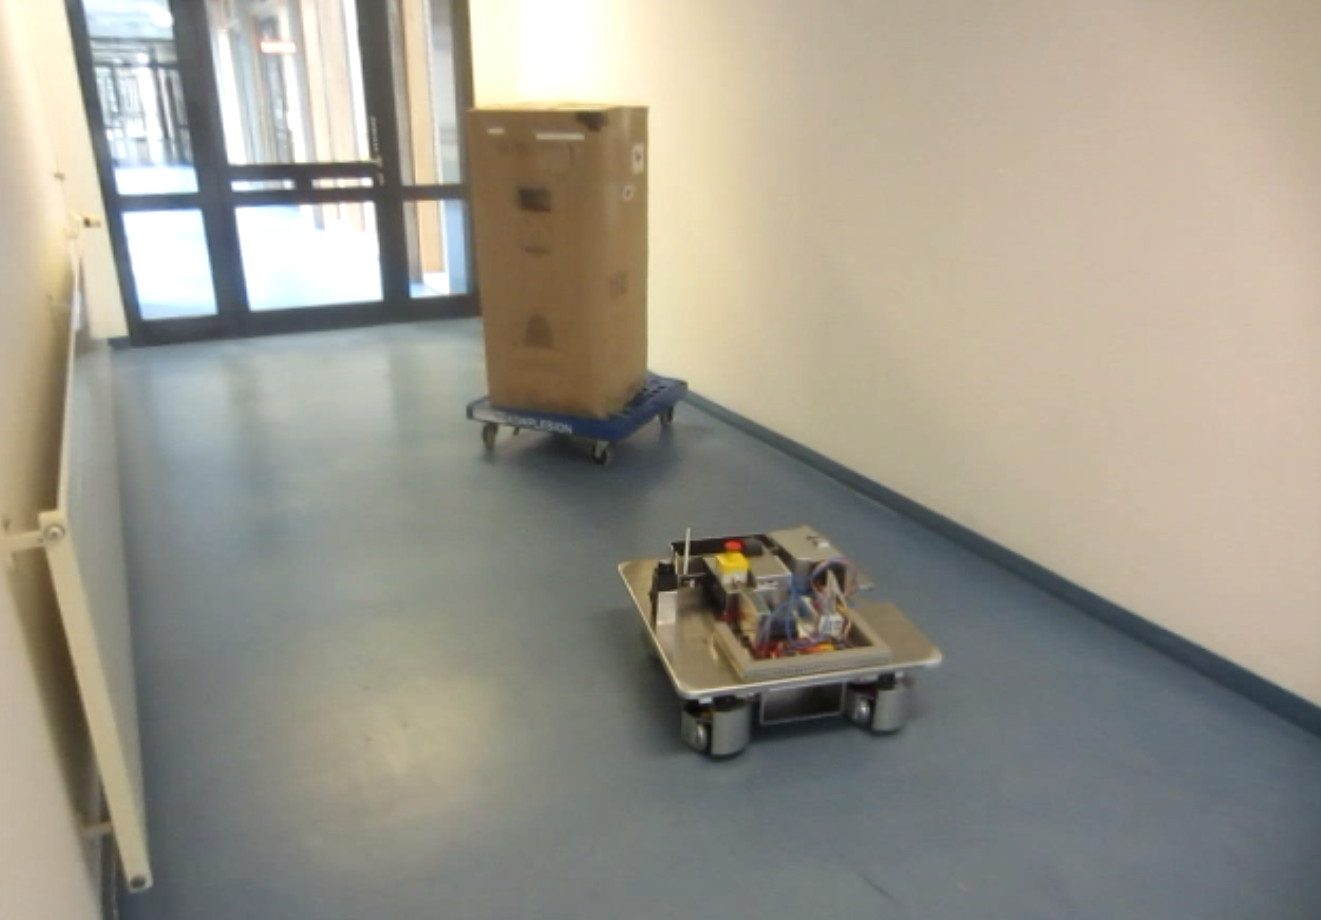
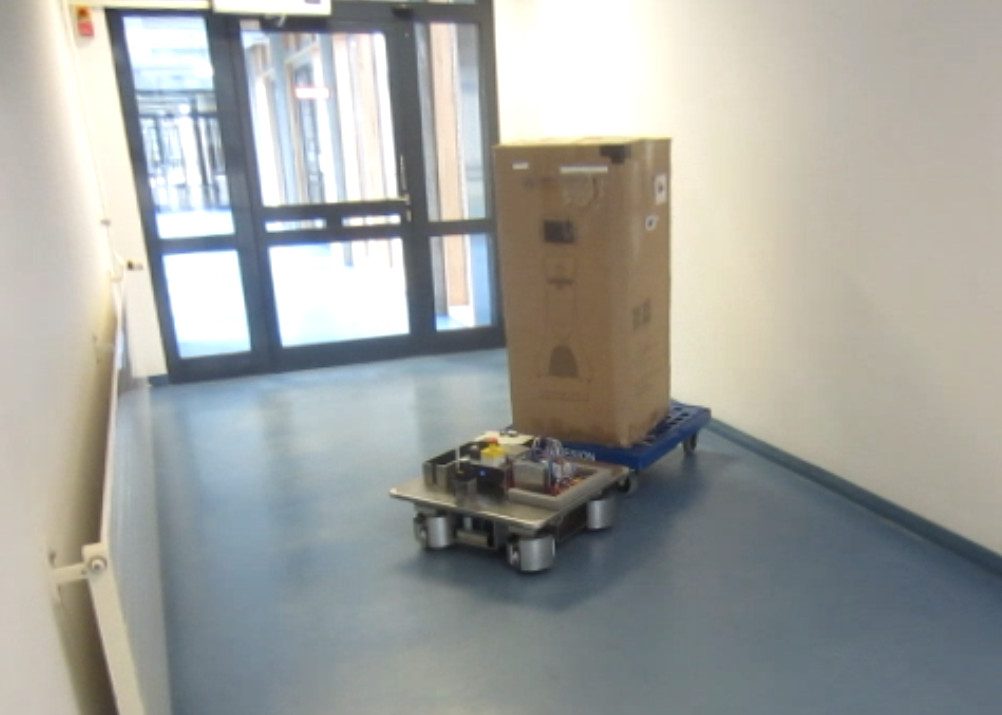
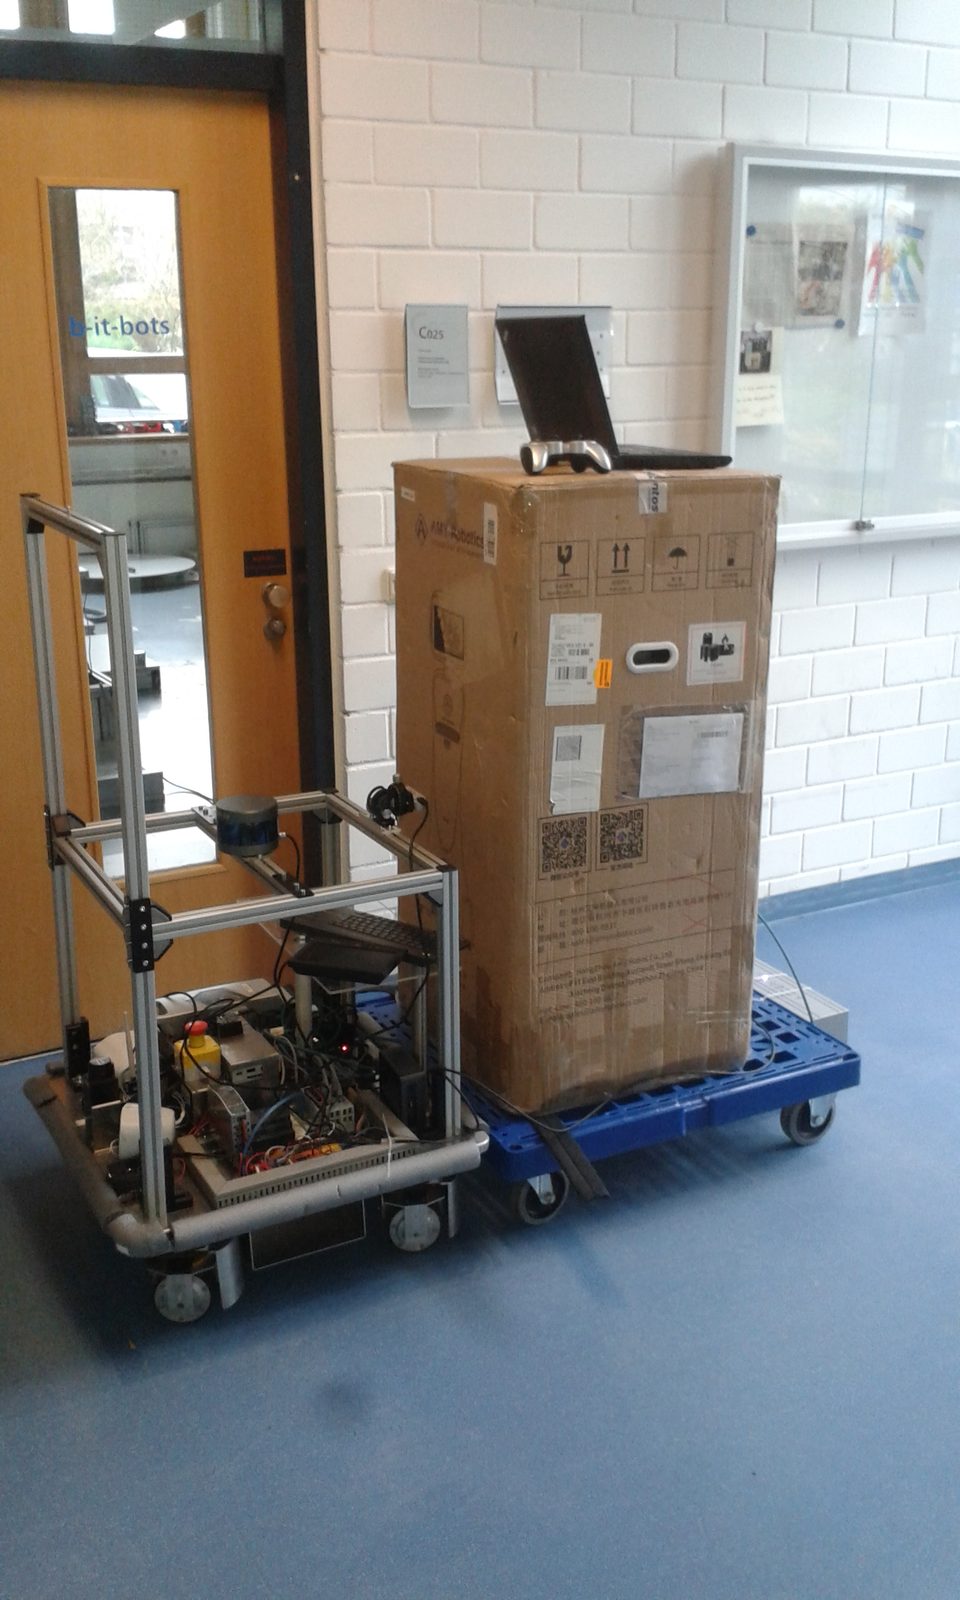
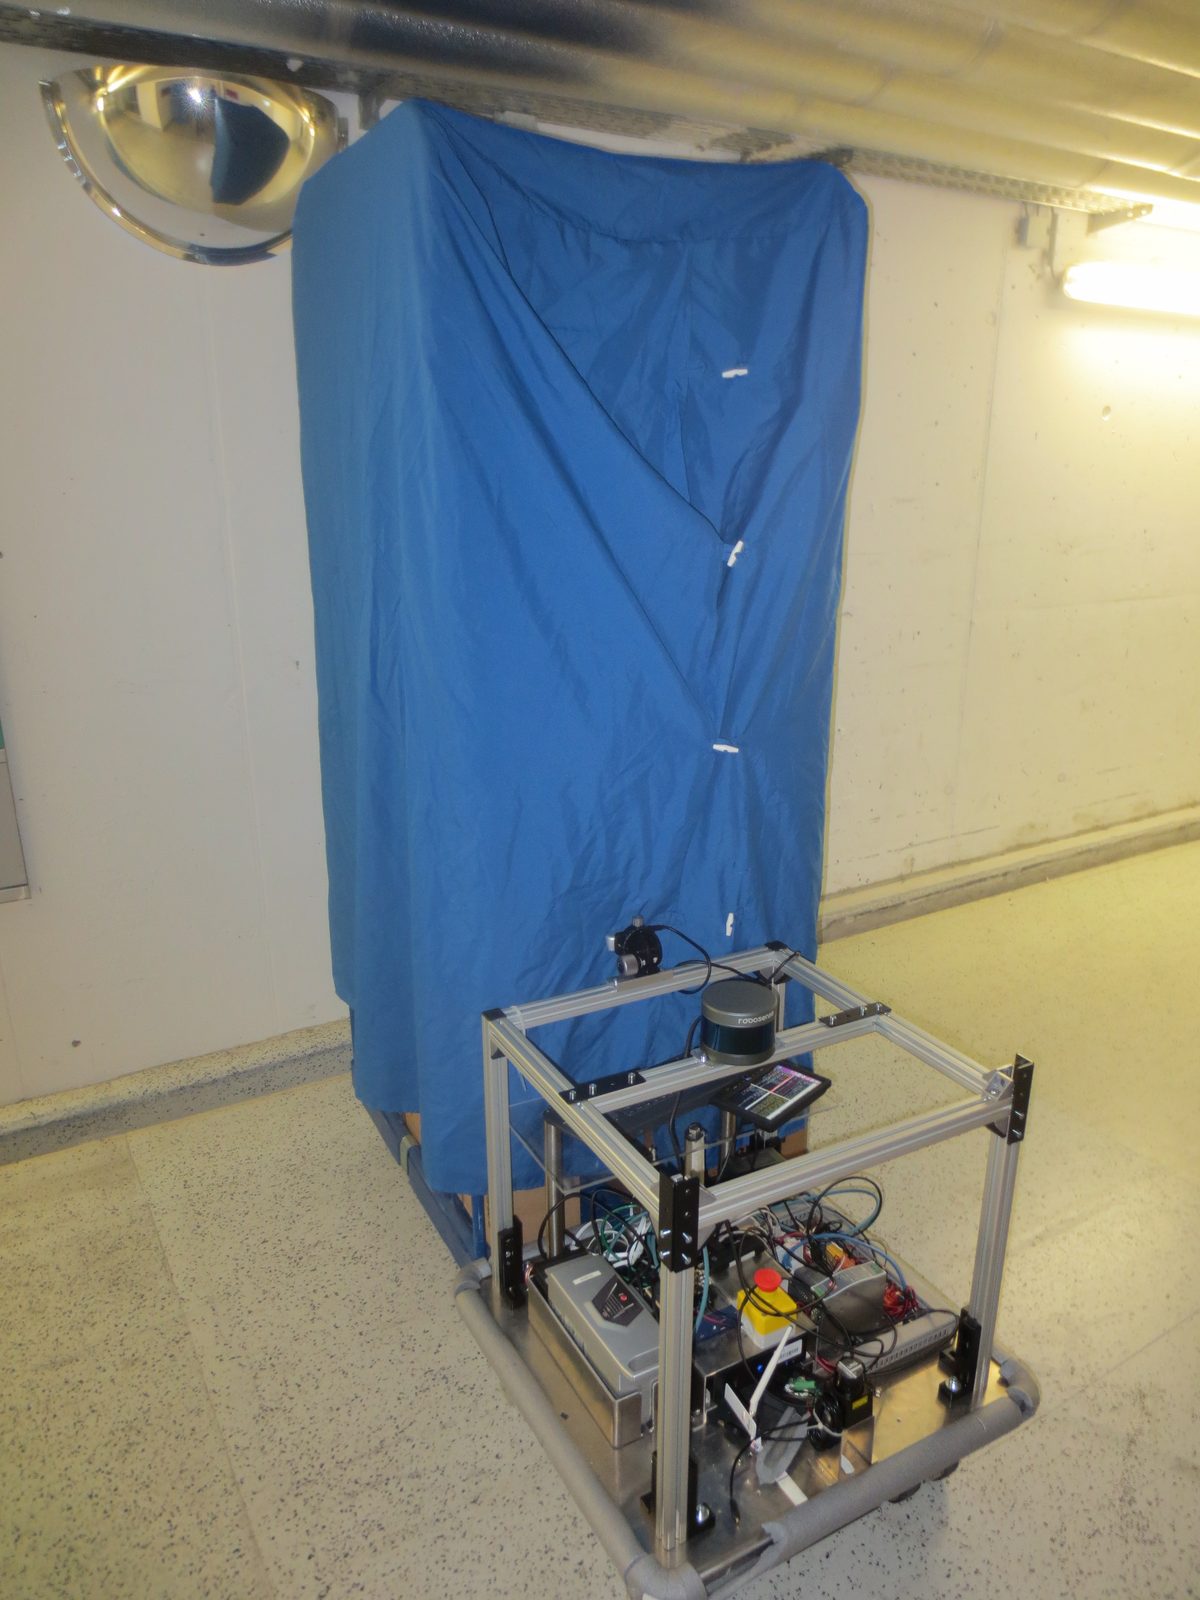
Proof-of-concept robot for autonomous transport of roll containers.
The majority of system tests have been carried out in a remote testing facility, observed by IP cameras. This type of testing works surprisingly well.
Tech: CNN-based load detection and depth camera based visual servoing, 2x 2D LiDAR, 1x 3D LiDAR (3D SLAM), 4x RGB-D camera, ROS
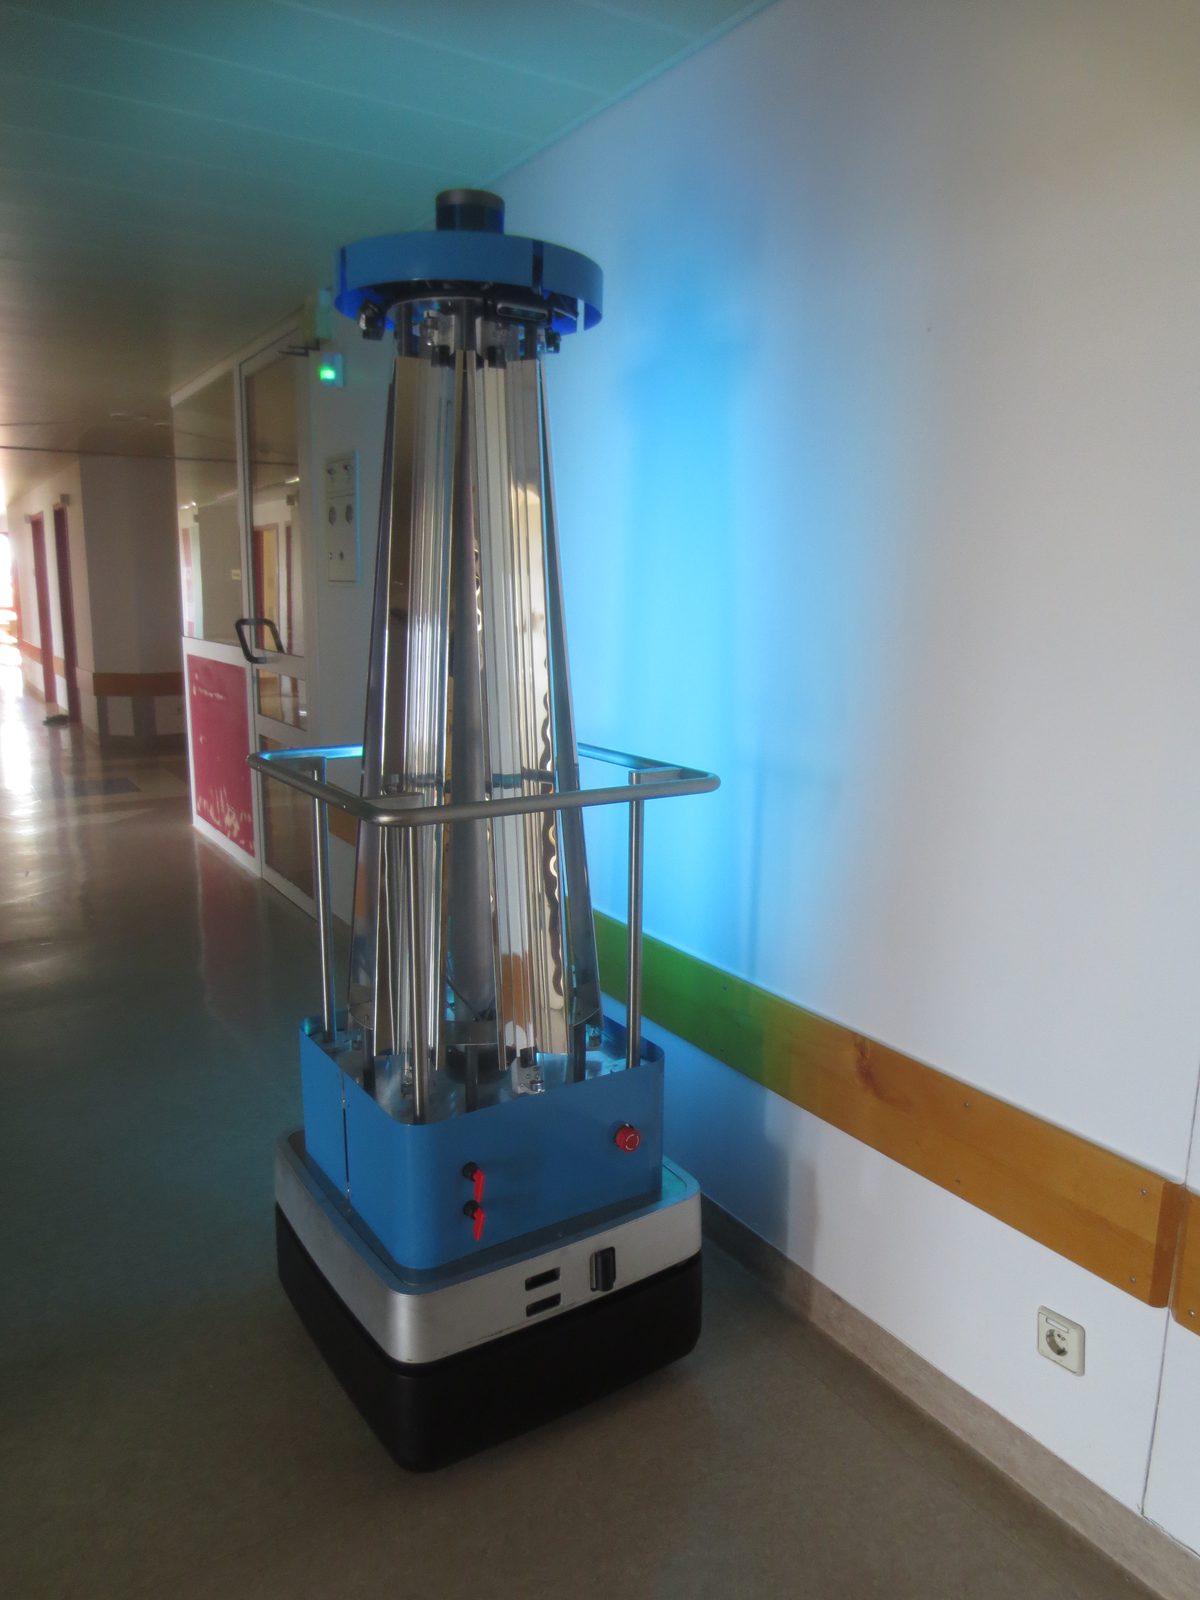
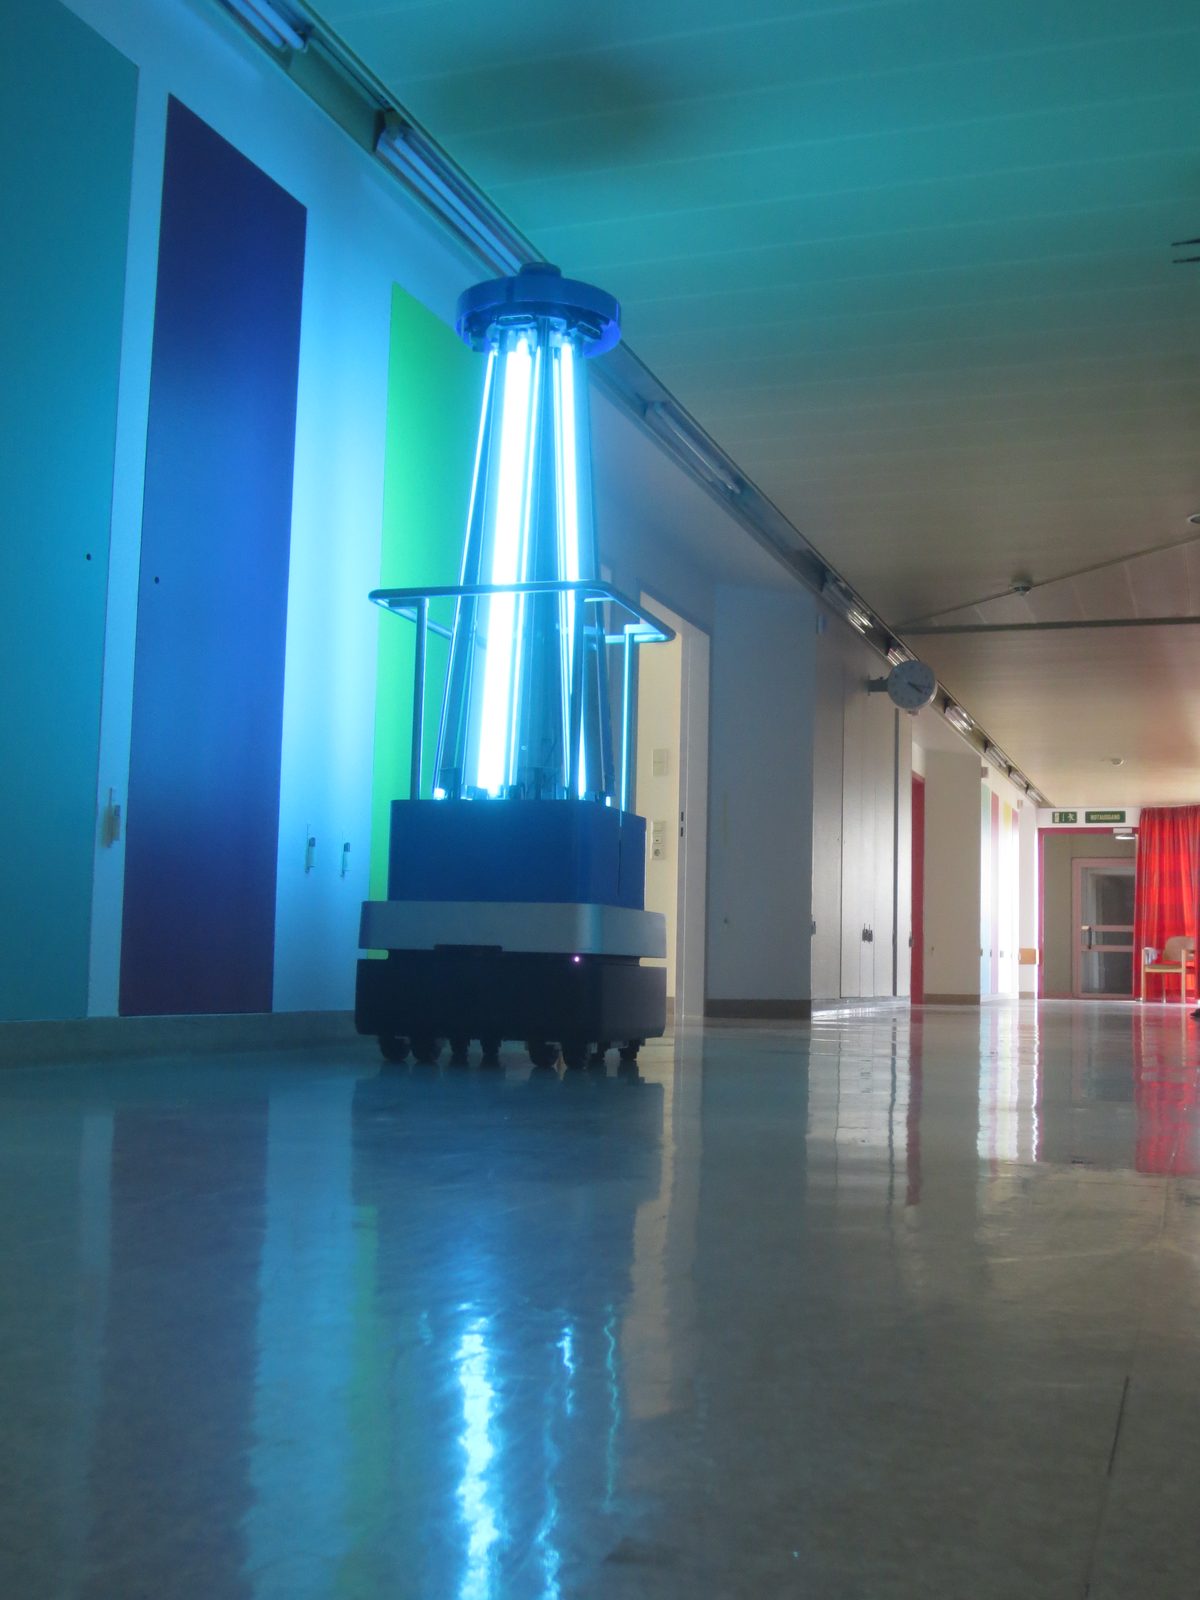
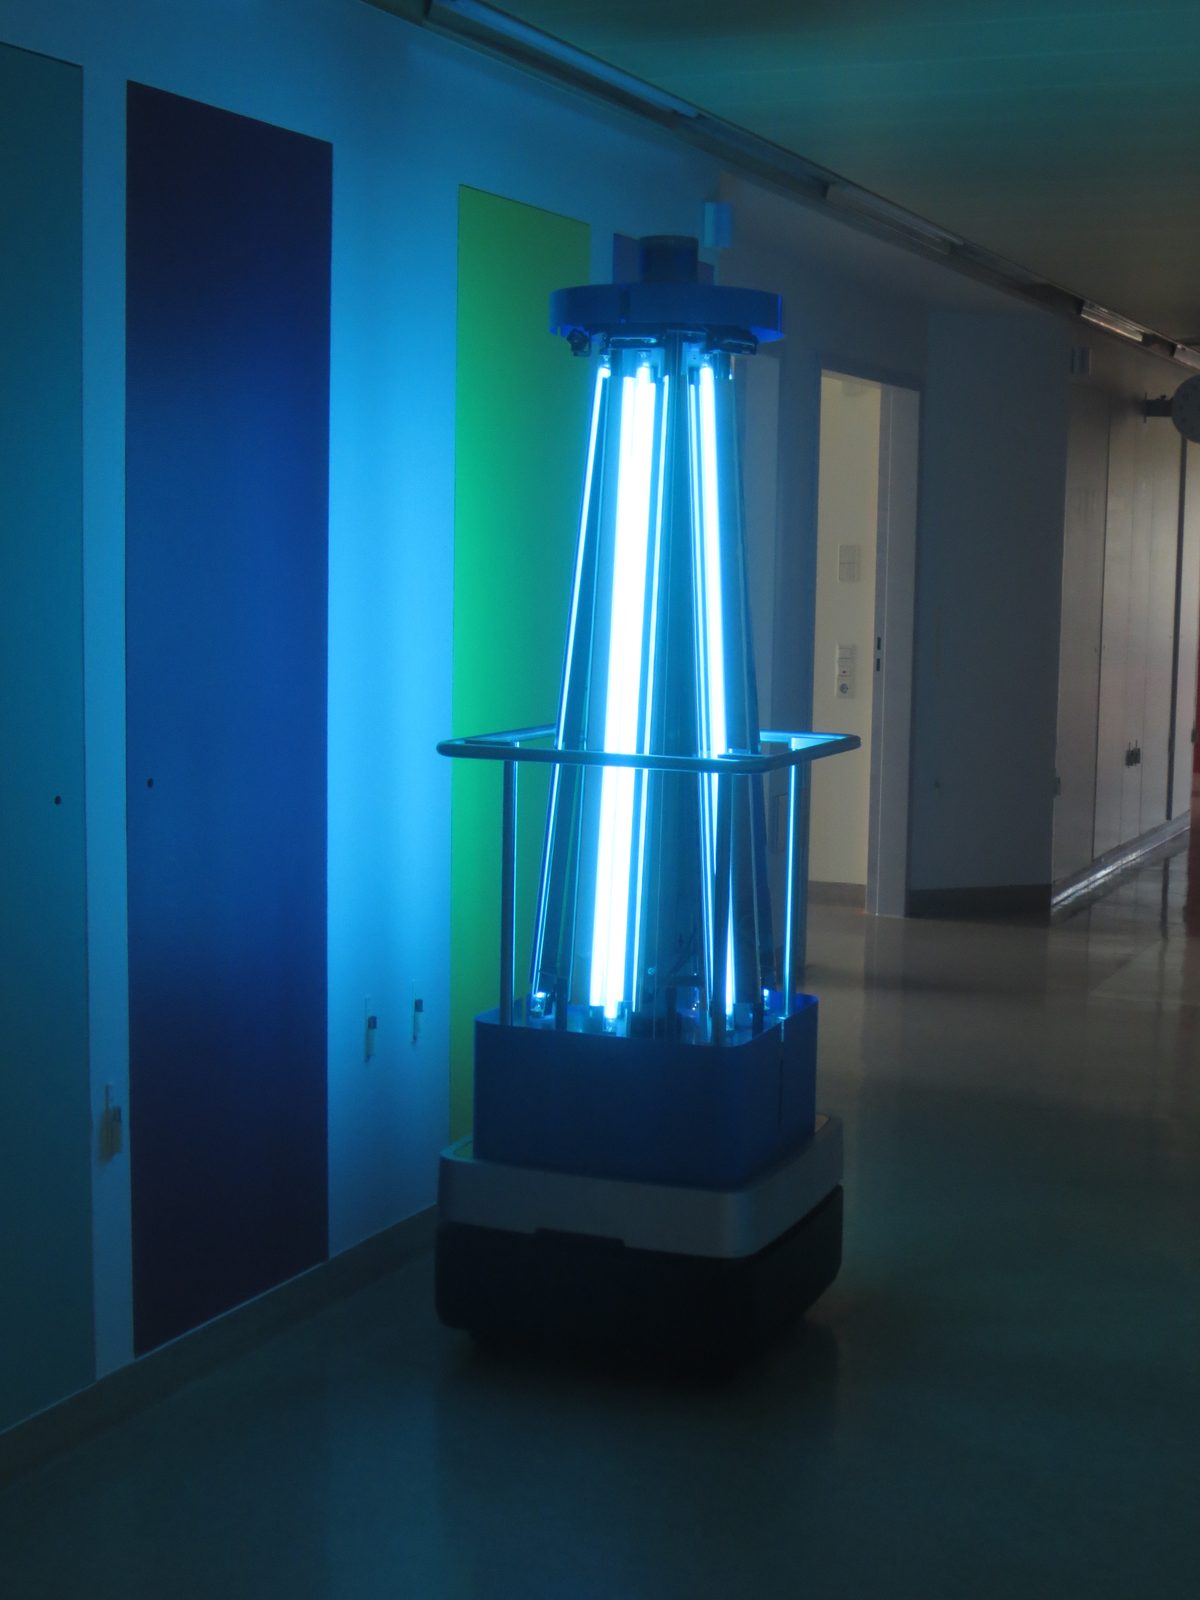
uvc_1
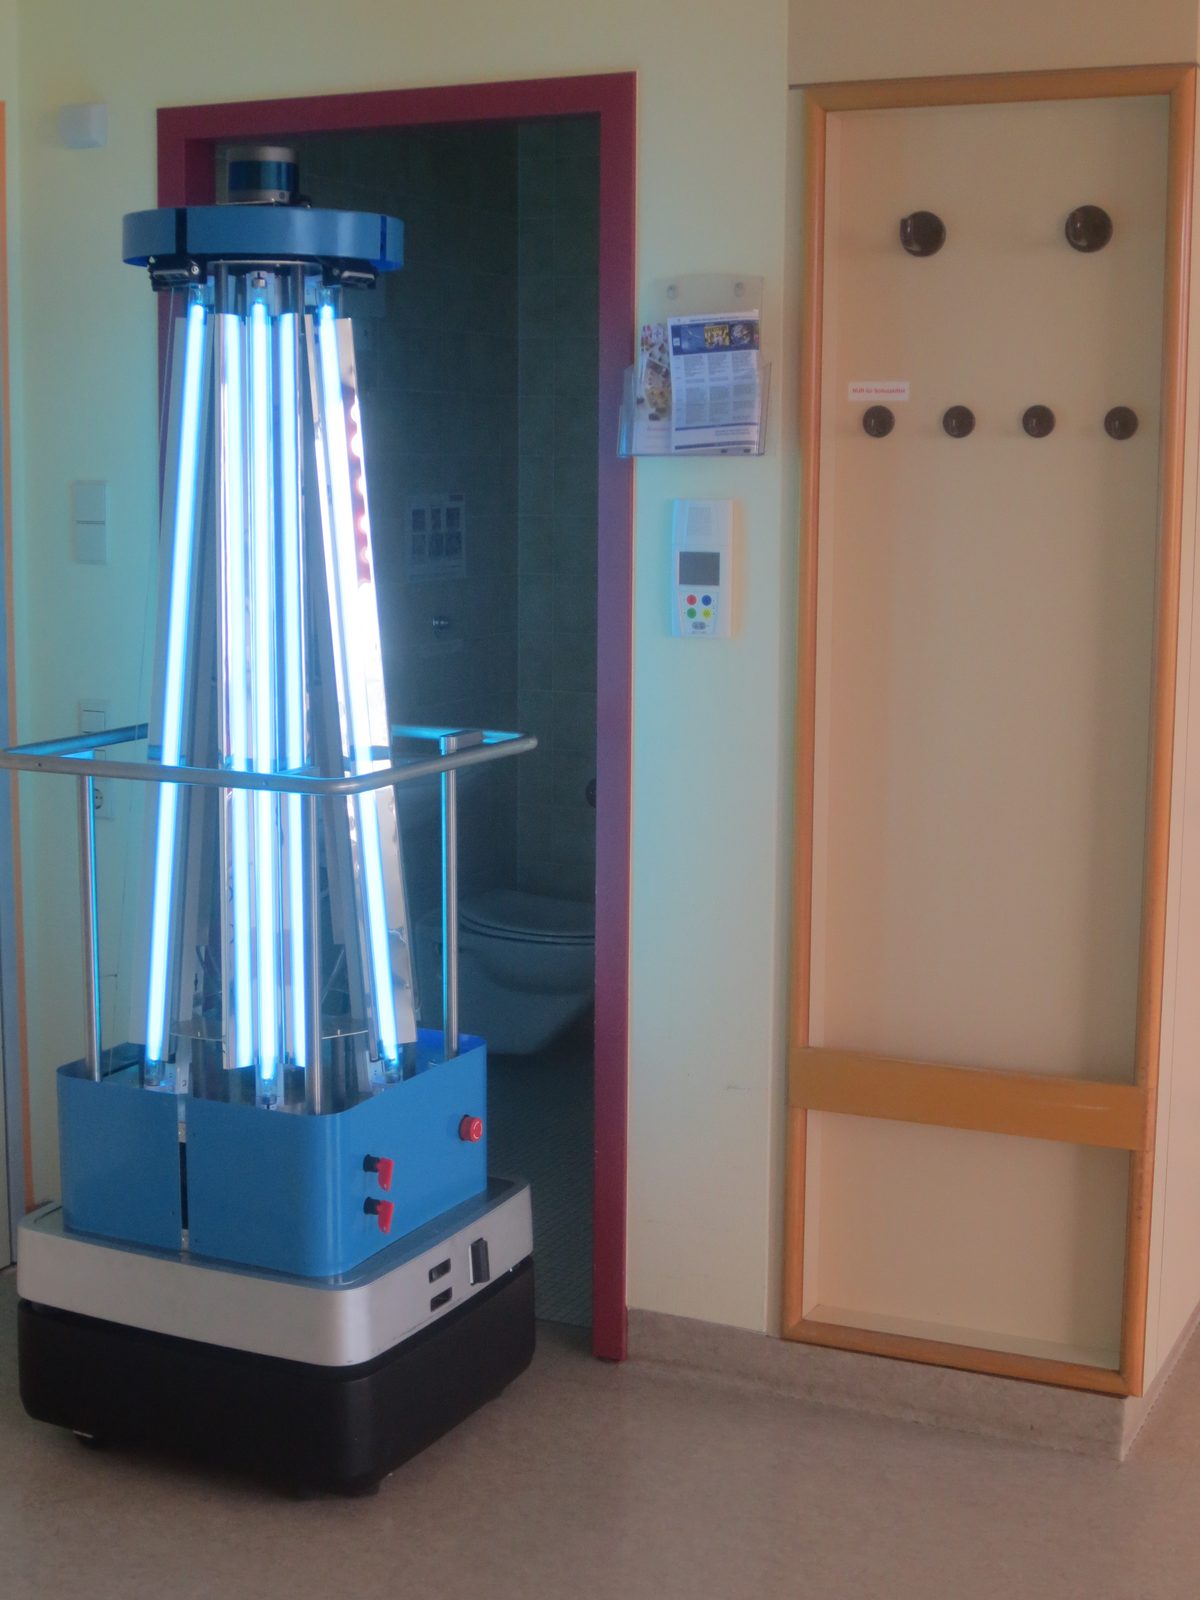
UV-C disinfection robot, developed as part of the DIH-HERO COVID-19 call. Disables lamps when persons are detected in camera images. Later used in the SESAME EU project on safe and secure multi-robot systems.
Tech: CNN-based person detection on Nvidia Jetson AGX Xavier on 4 RGB cameras, 2x 2D LiDAR, 1x 3D LiDAR, 4x RGB-D camera, ROS
WASP and HAWK
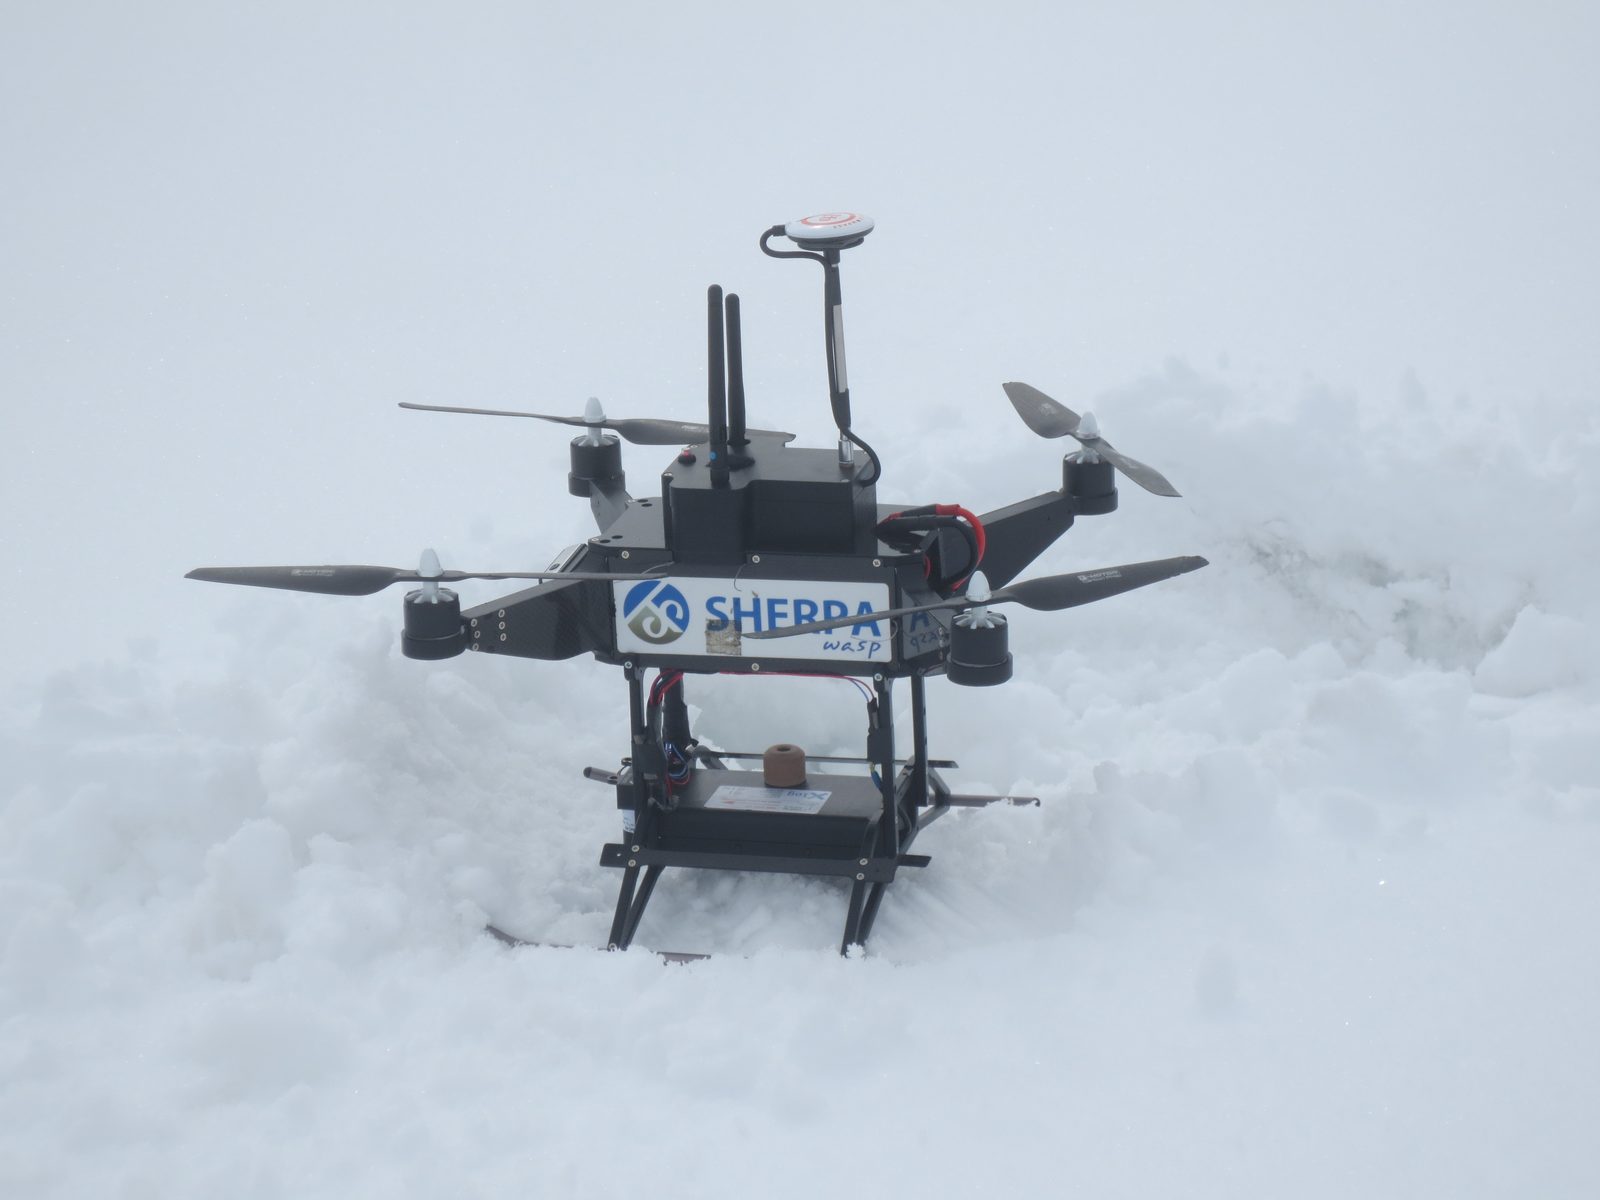
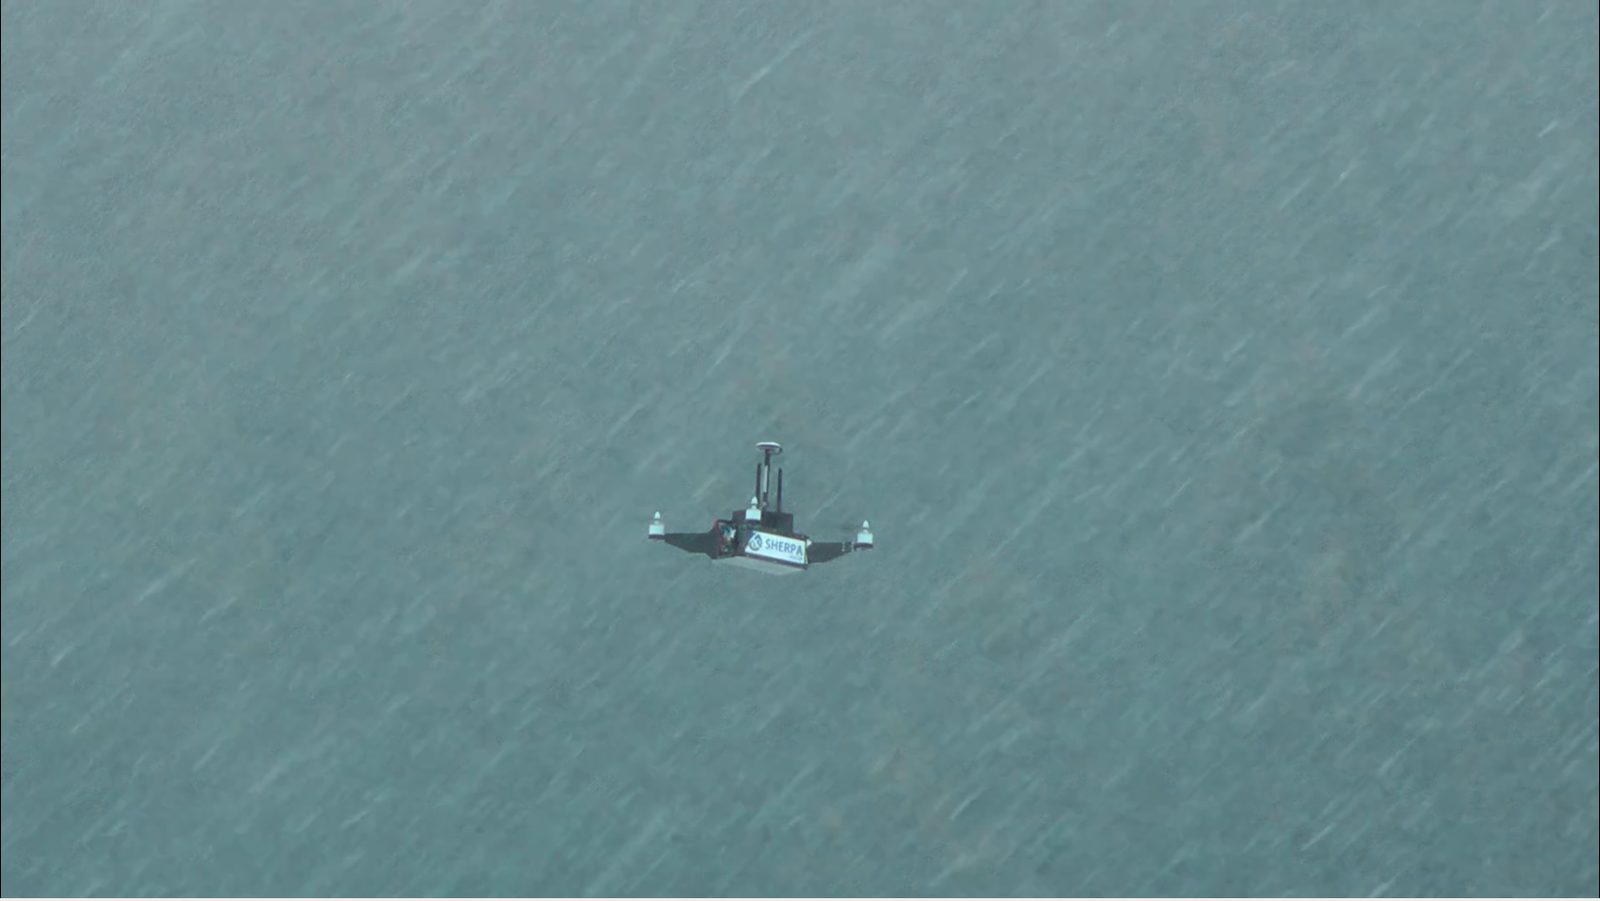
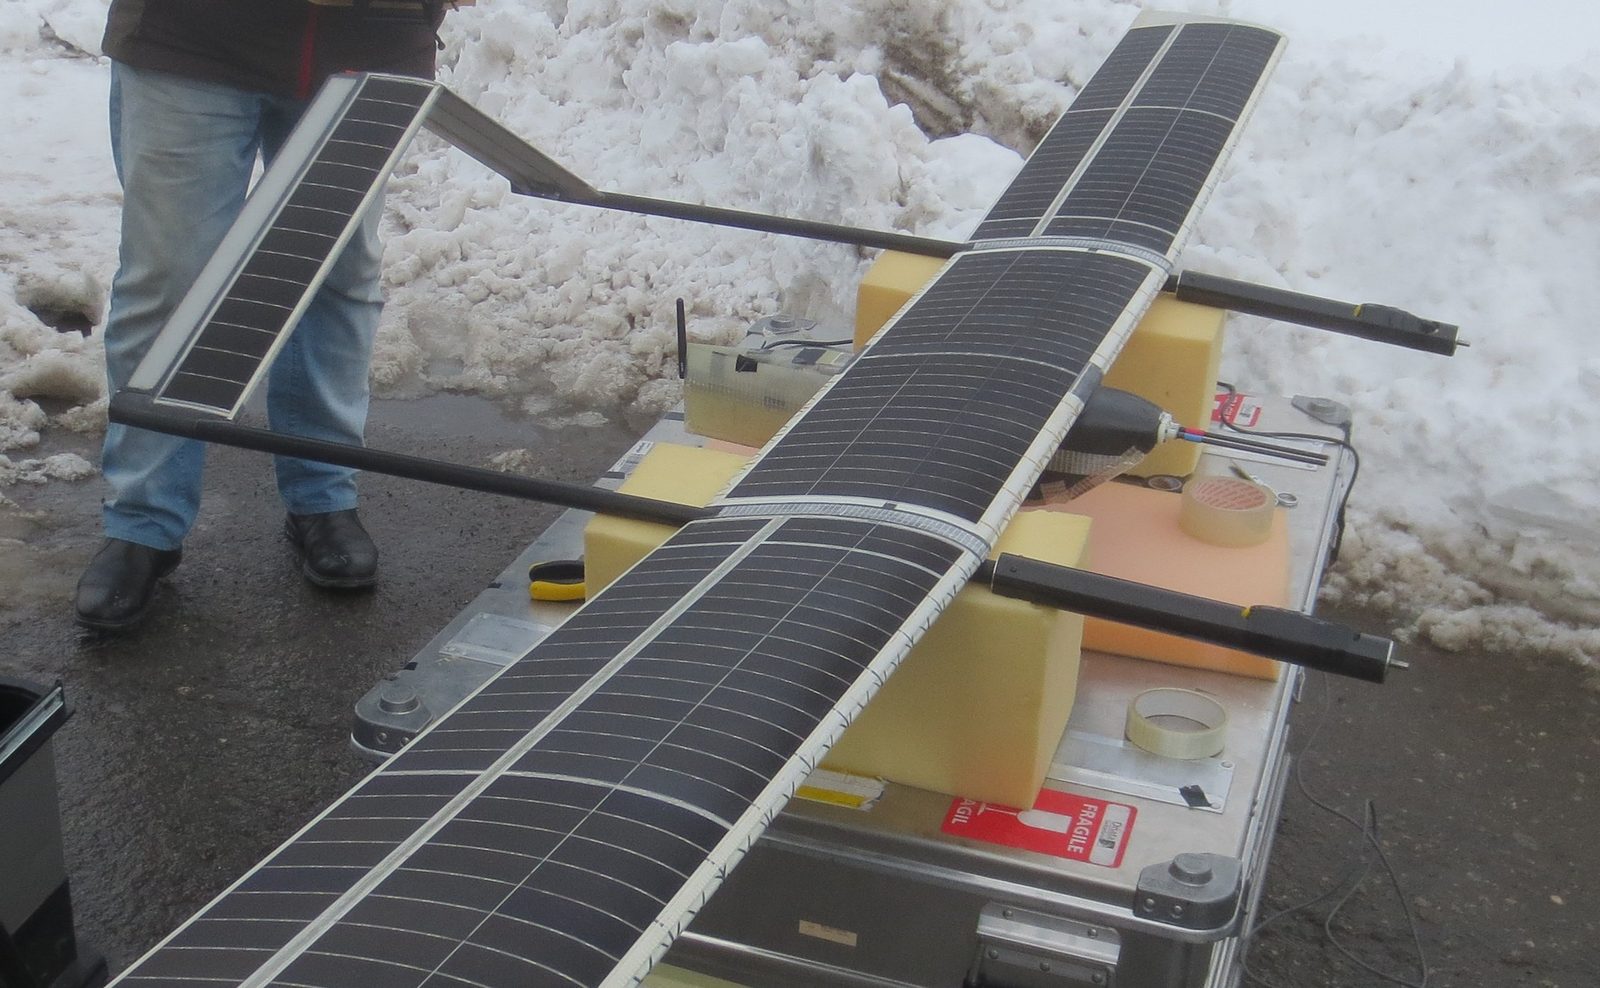
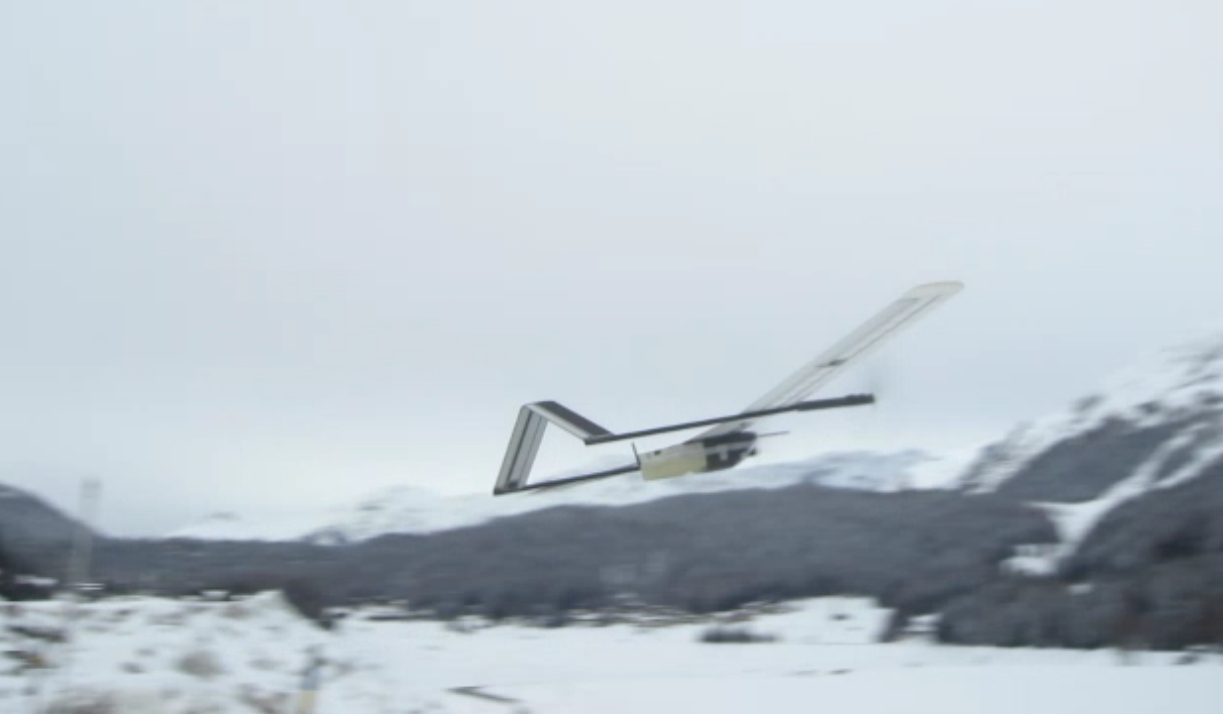
"Wasp" and "hawk" UAVs, developed by partners in the SHERPA EU project on alpine rescue scenarios. I contributed the Digital Cognitive Map (DCM) for a team of heterogeneous rescue robots.
Picture of Wasp taken during a test flight in Davos. Two of the UAVs flew into a sudden snowstorm and disappeared - out of sight, out of hearing range. Everyone on the team stood there waiting to hear them again. When they came back, the mission was completed as planned :)
RUFUS
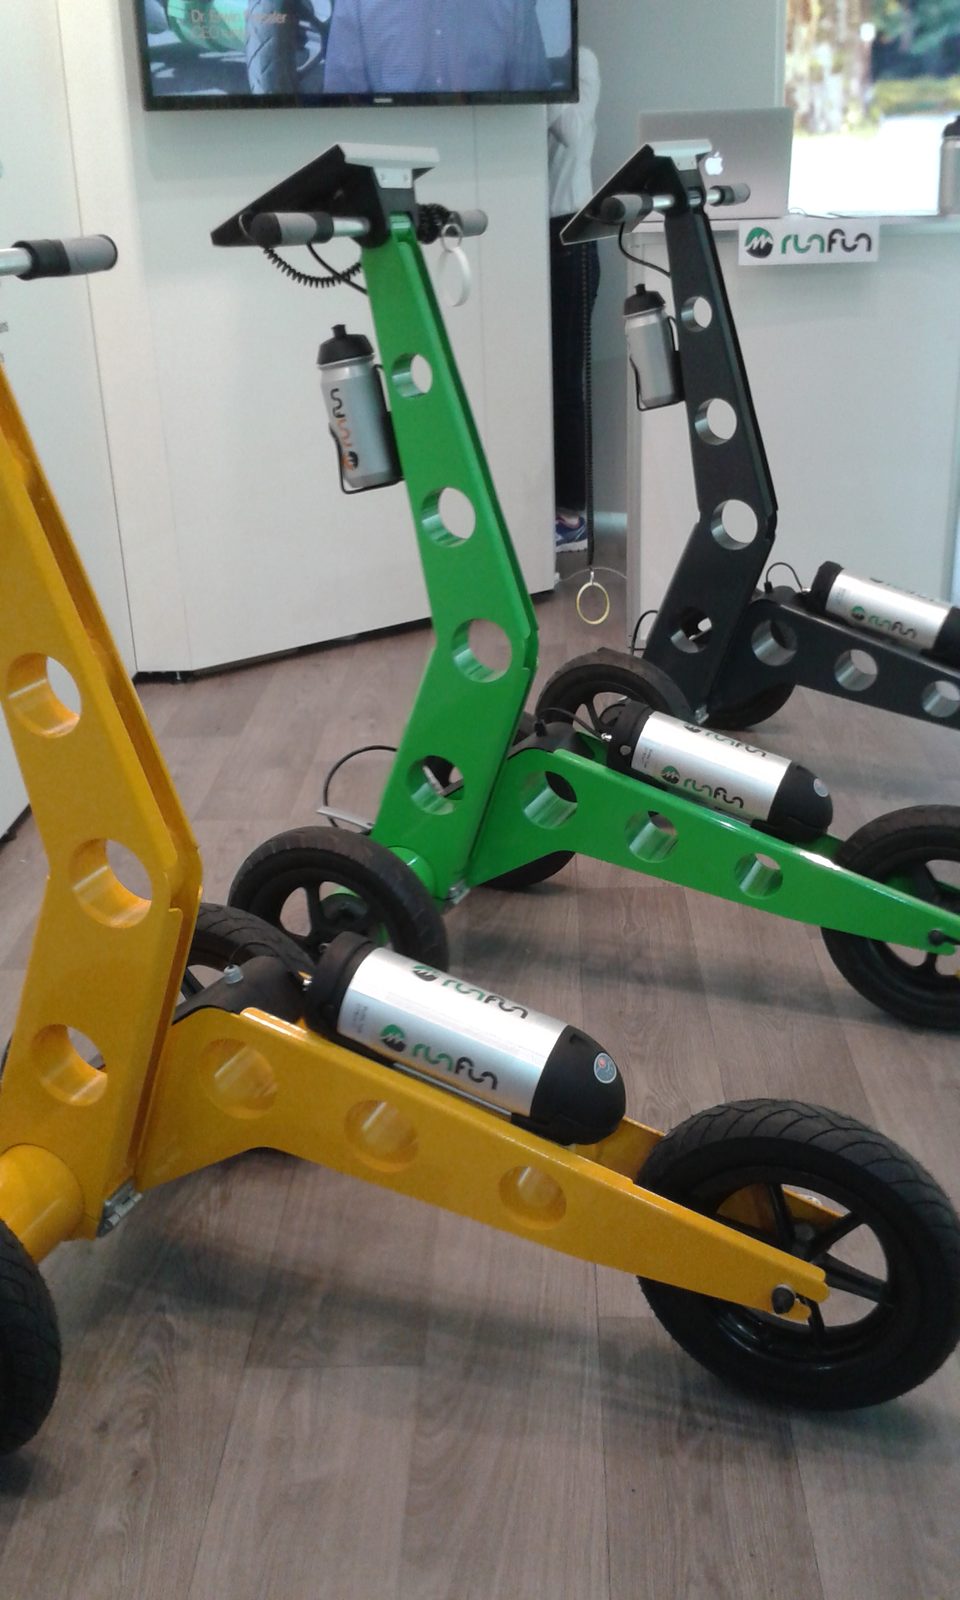
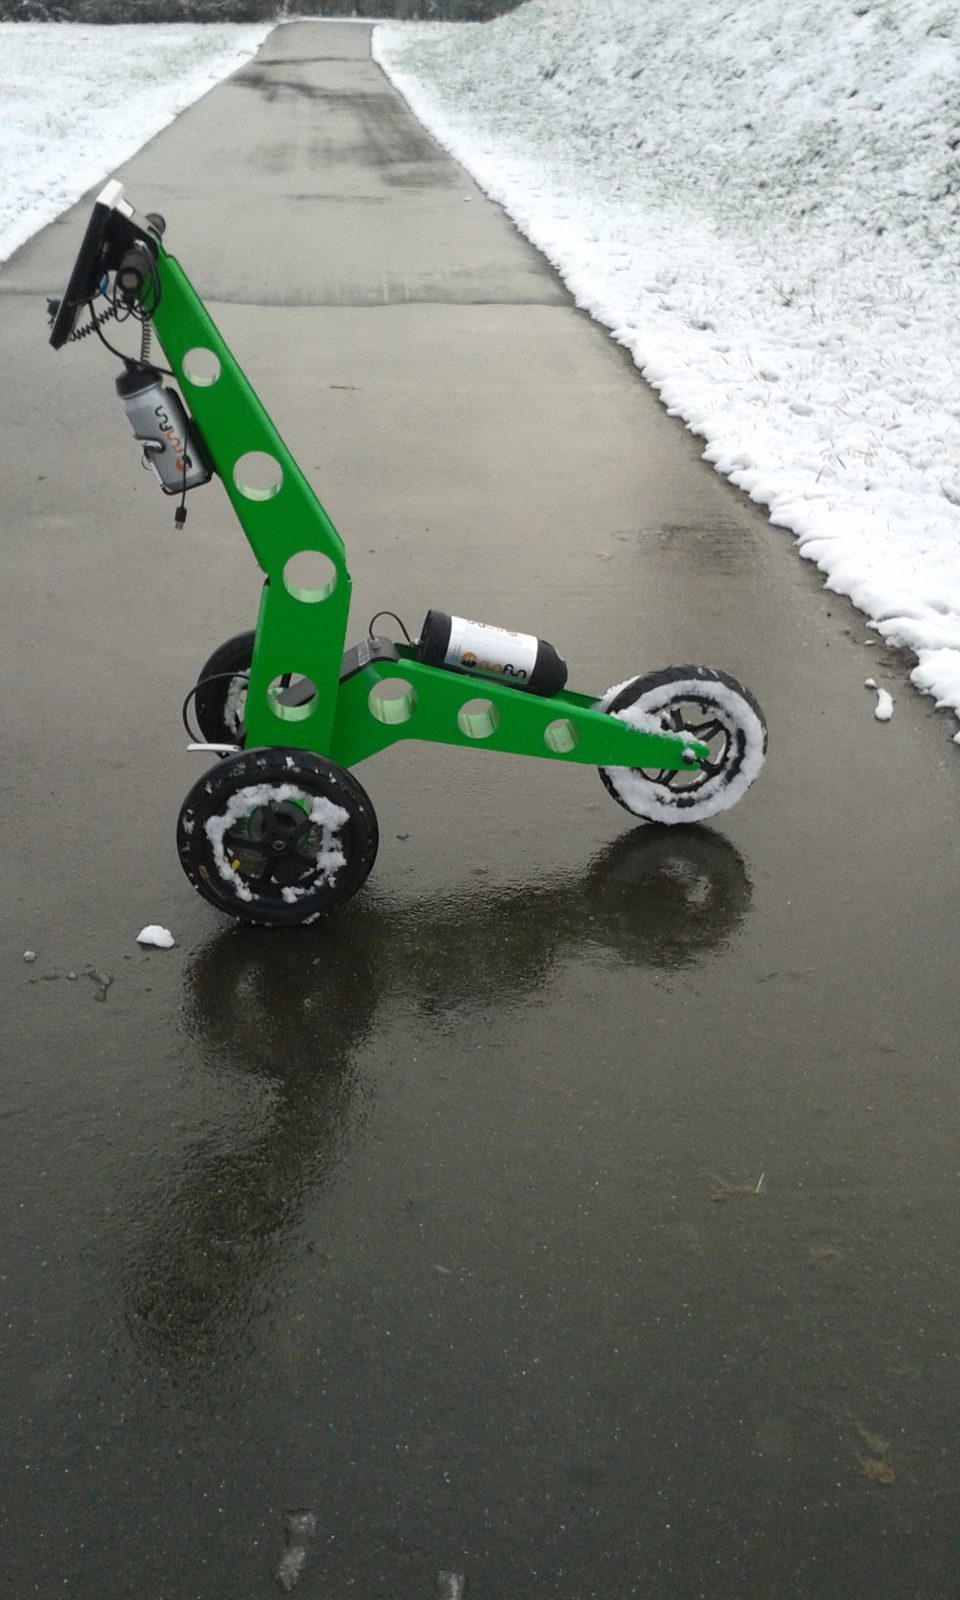
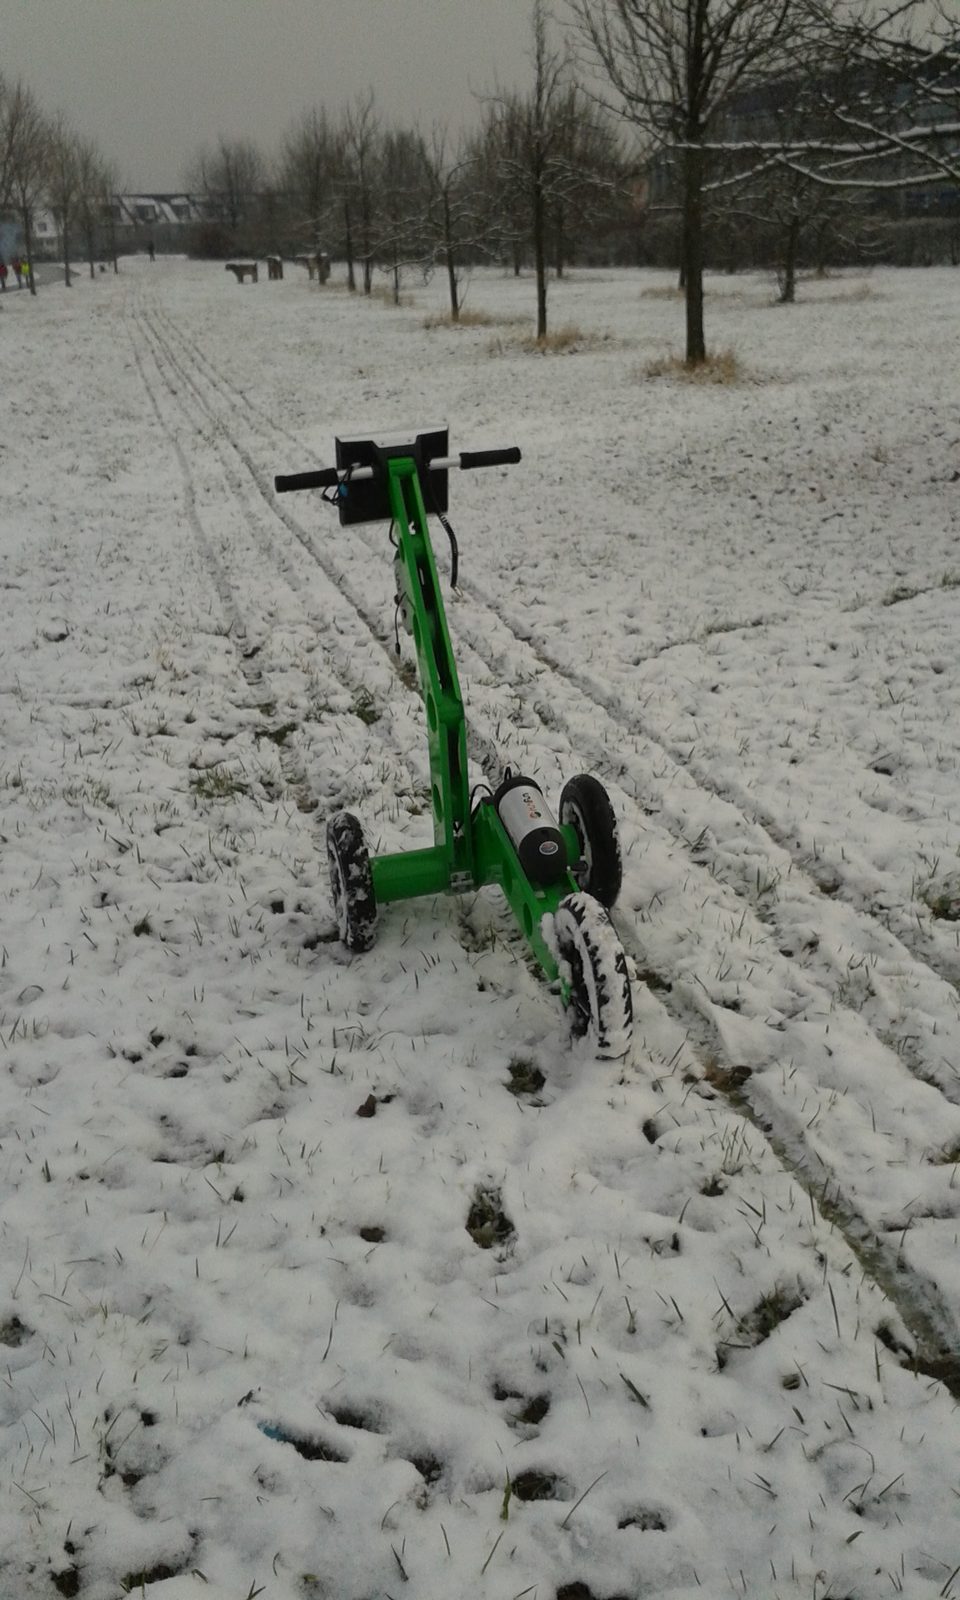
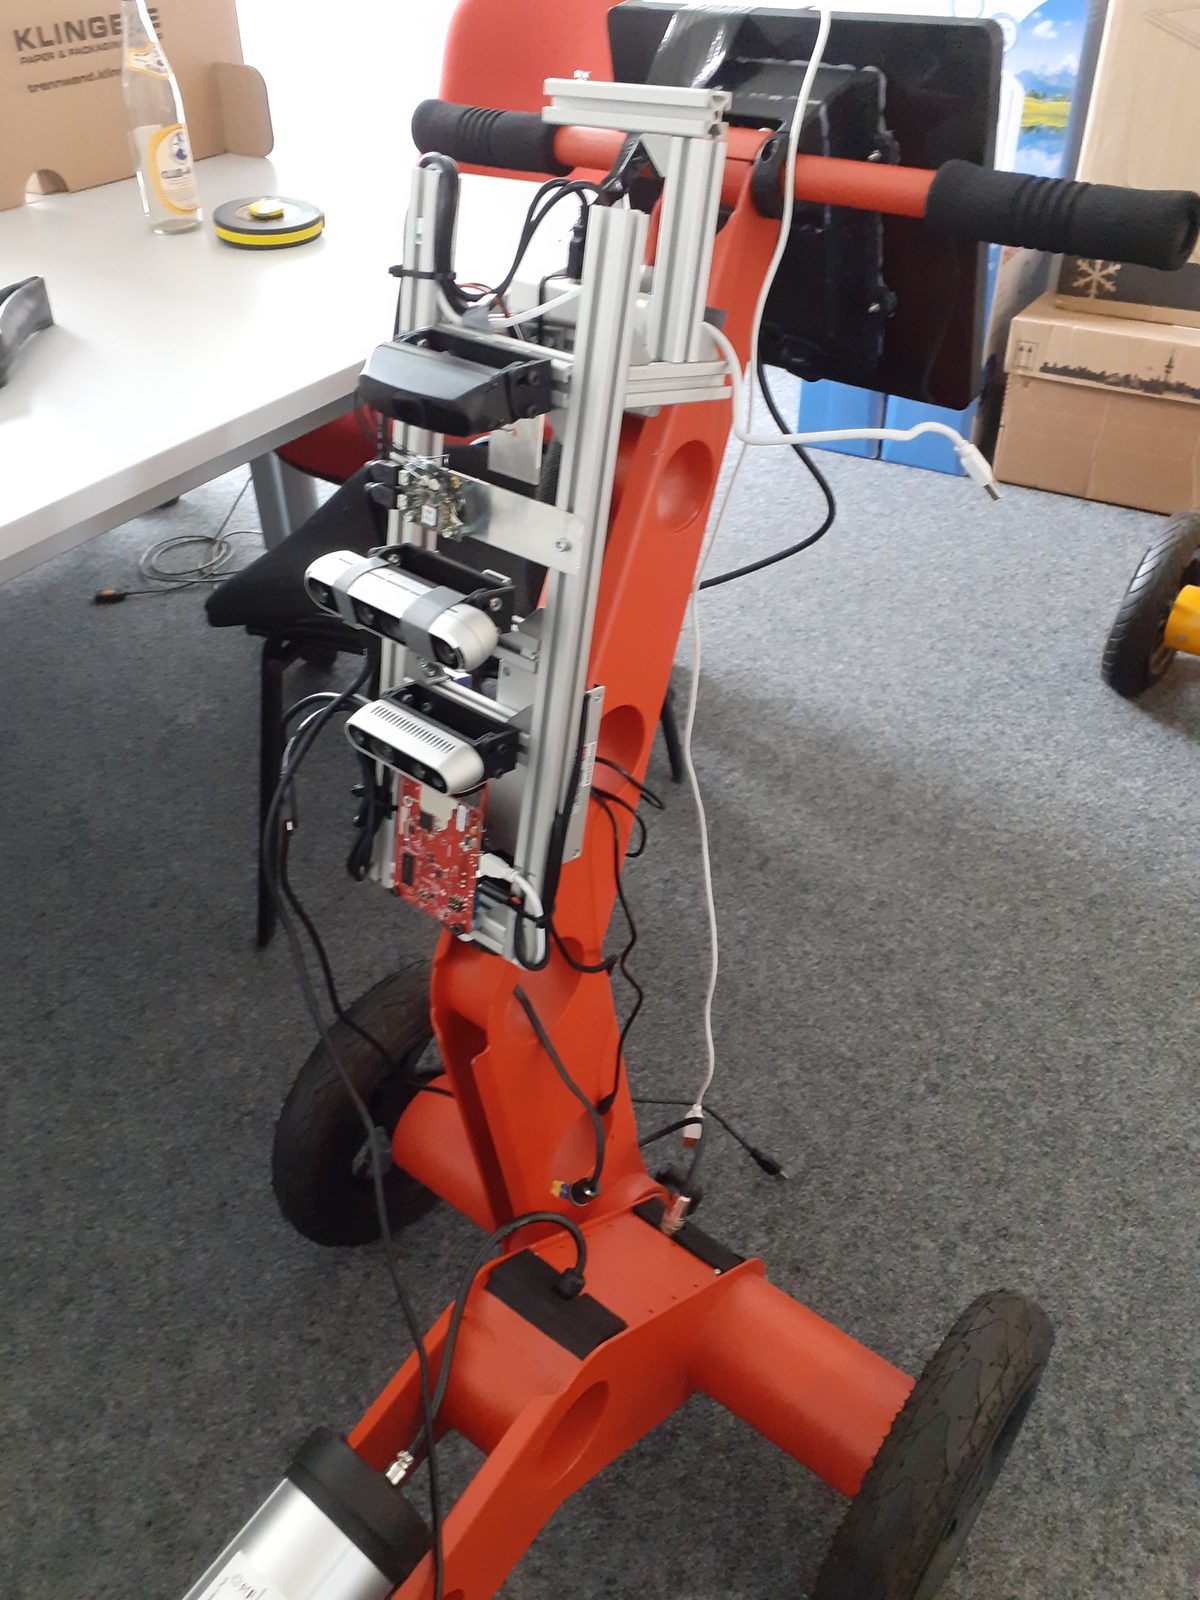
RUFUS is a running coach. It runs in front of the user and provides an optimal velocity control based on heart rate measurements. Image with red RUFUS shows attached sensor rack used during development of the autopilot for the ROBLIN project for blind runners.
Tech: Plain C++ on ARM Cortex-A8 and Android app as UI. Autopilot version: Nvidia Jetson AGX Xavier, RGB-D camera, GNSS, mmWave radar
youBot
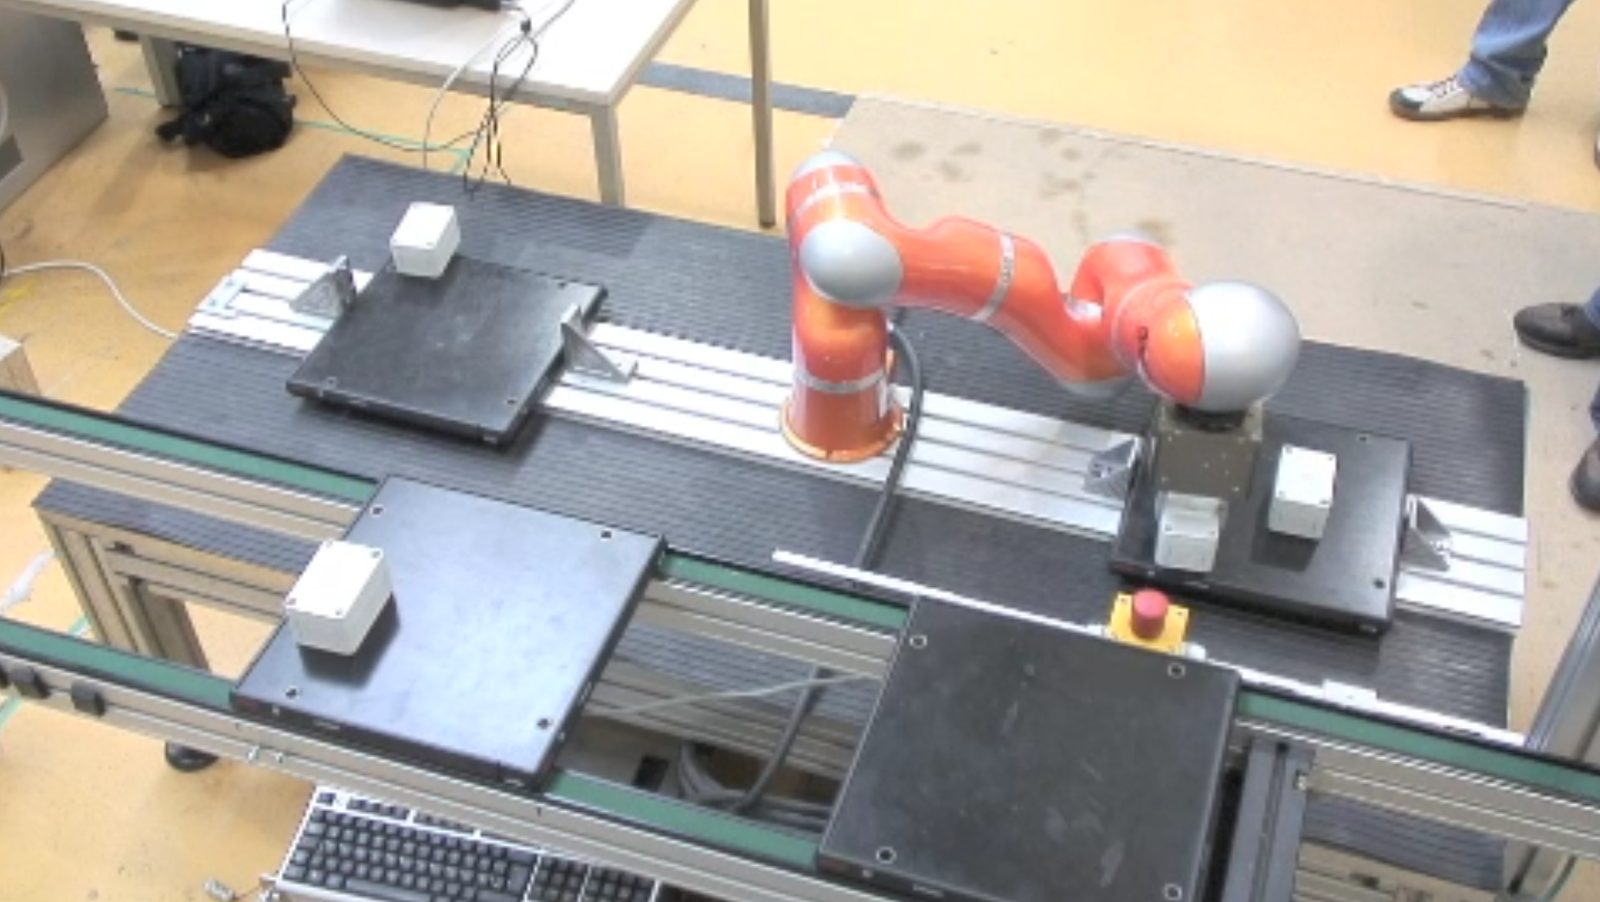
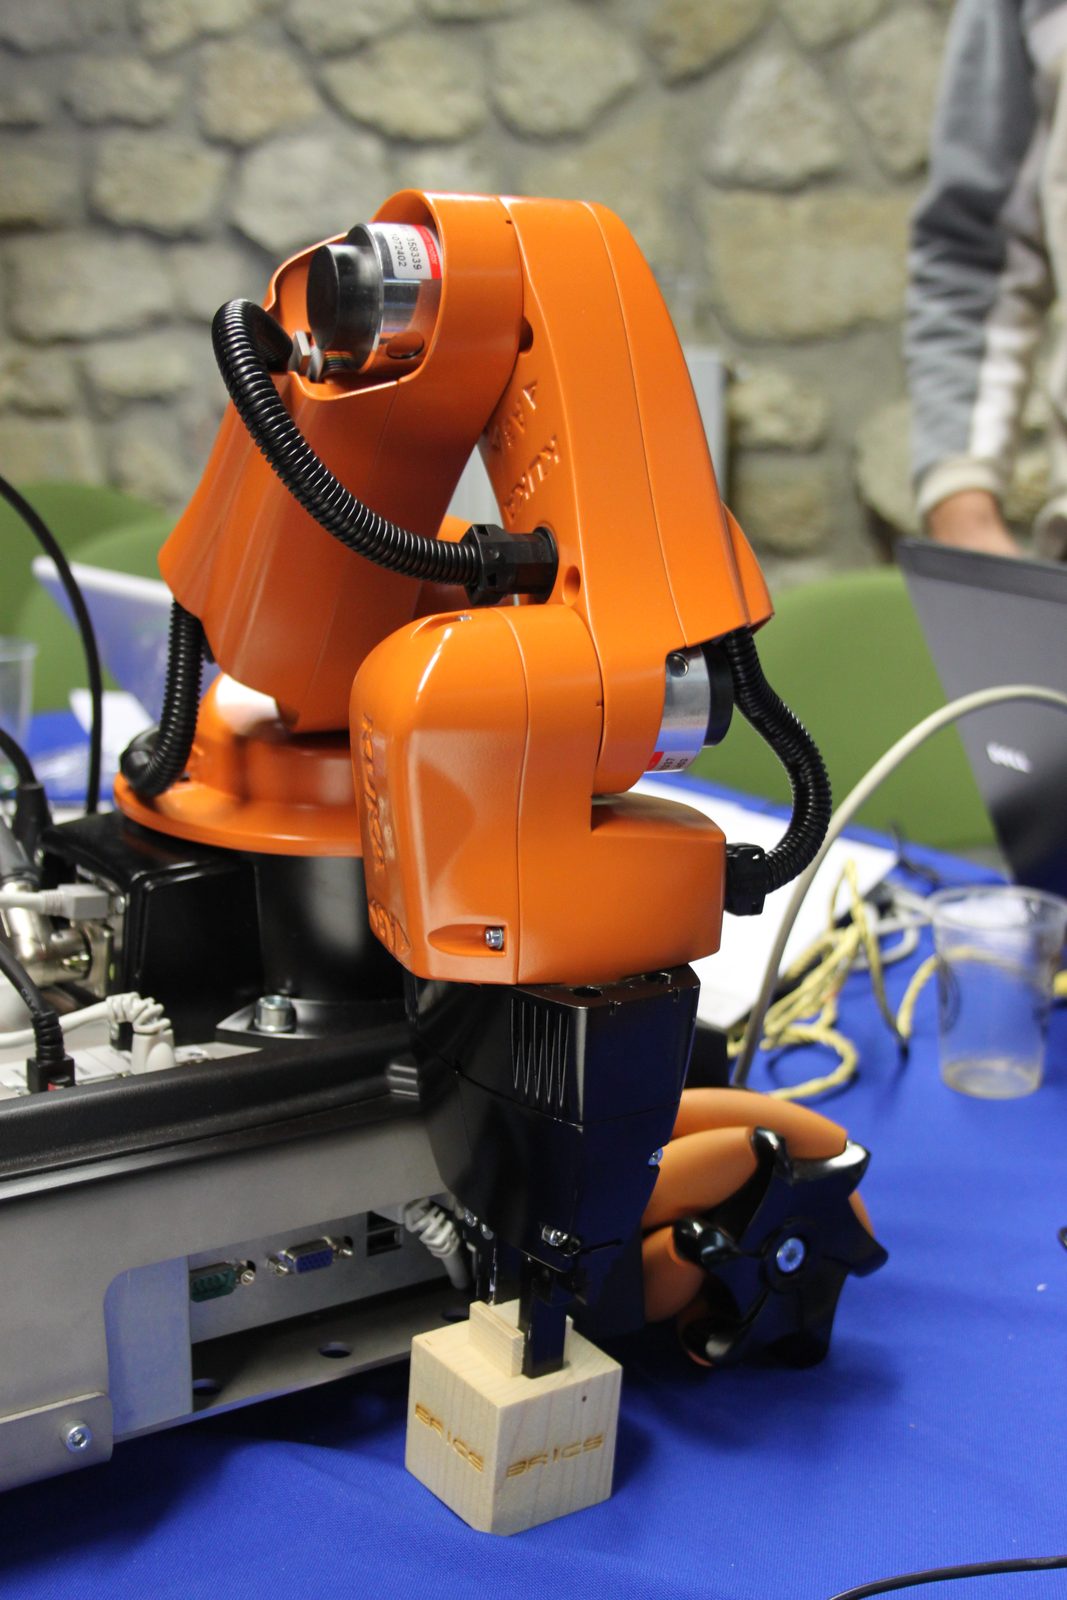
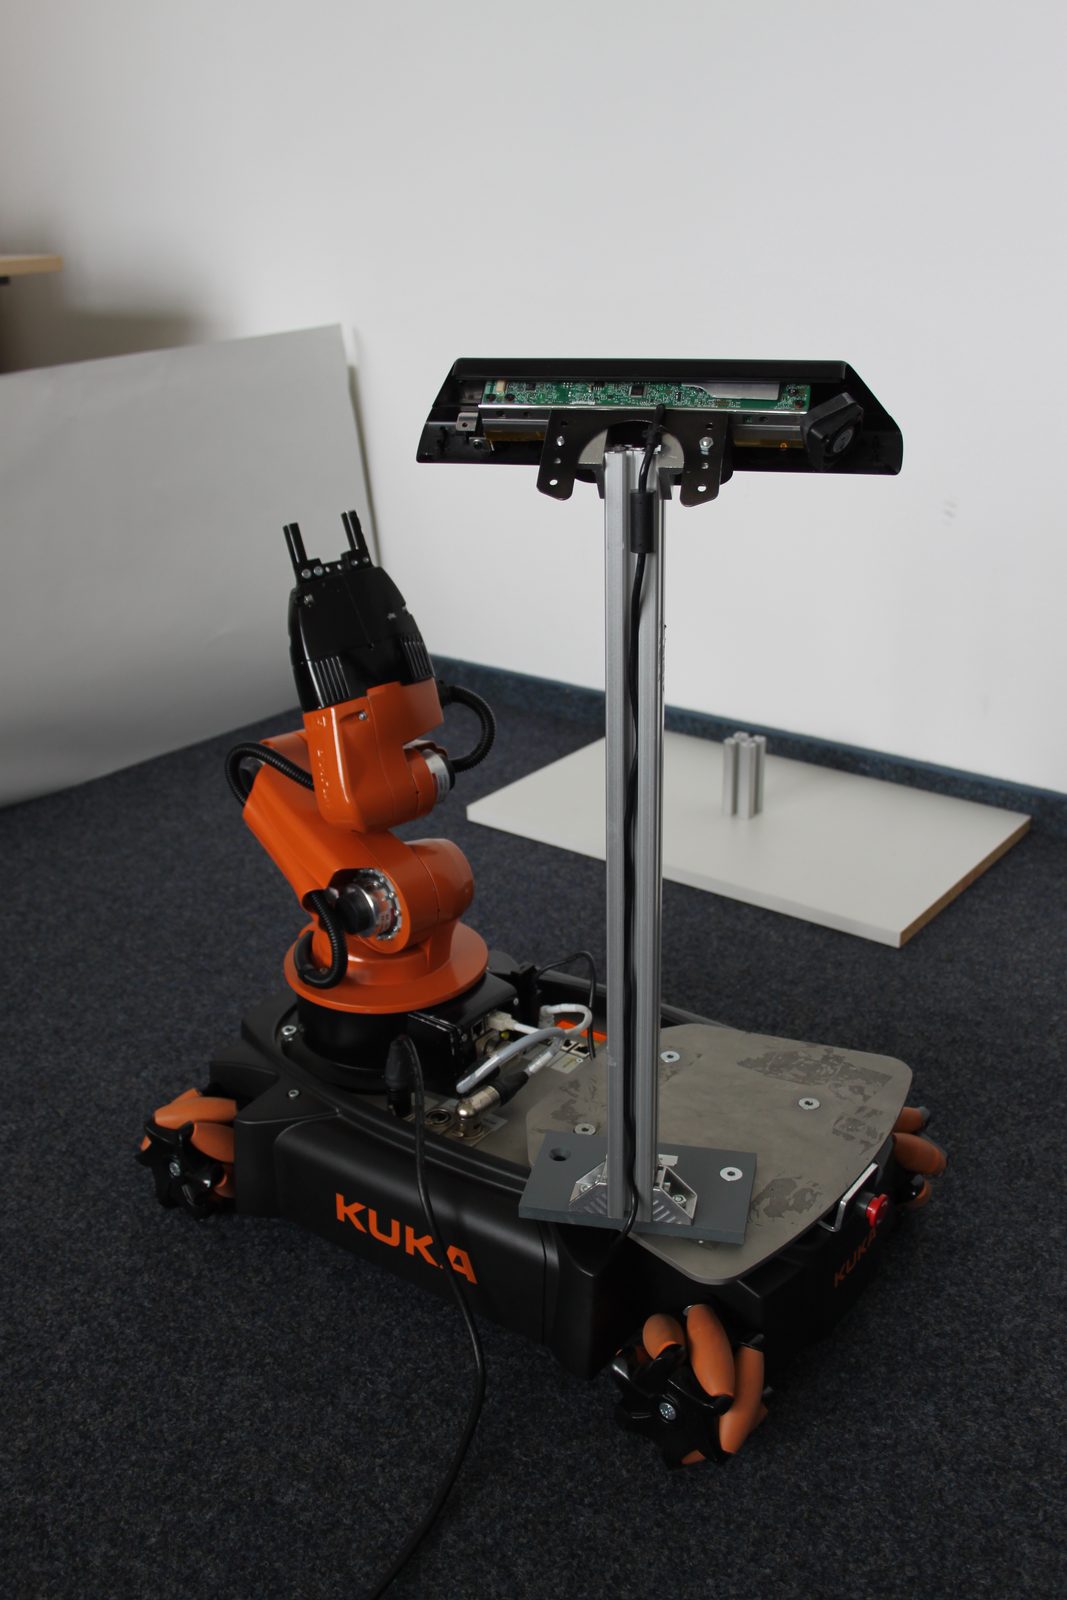
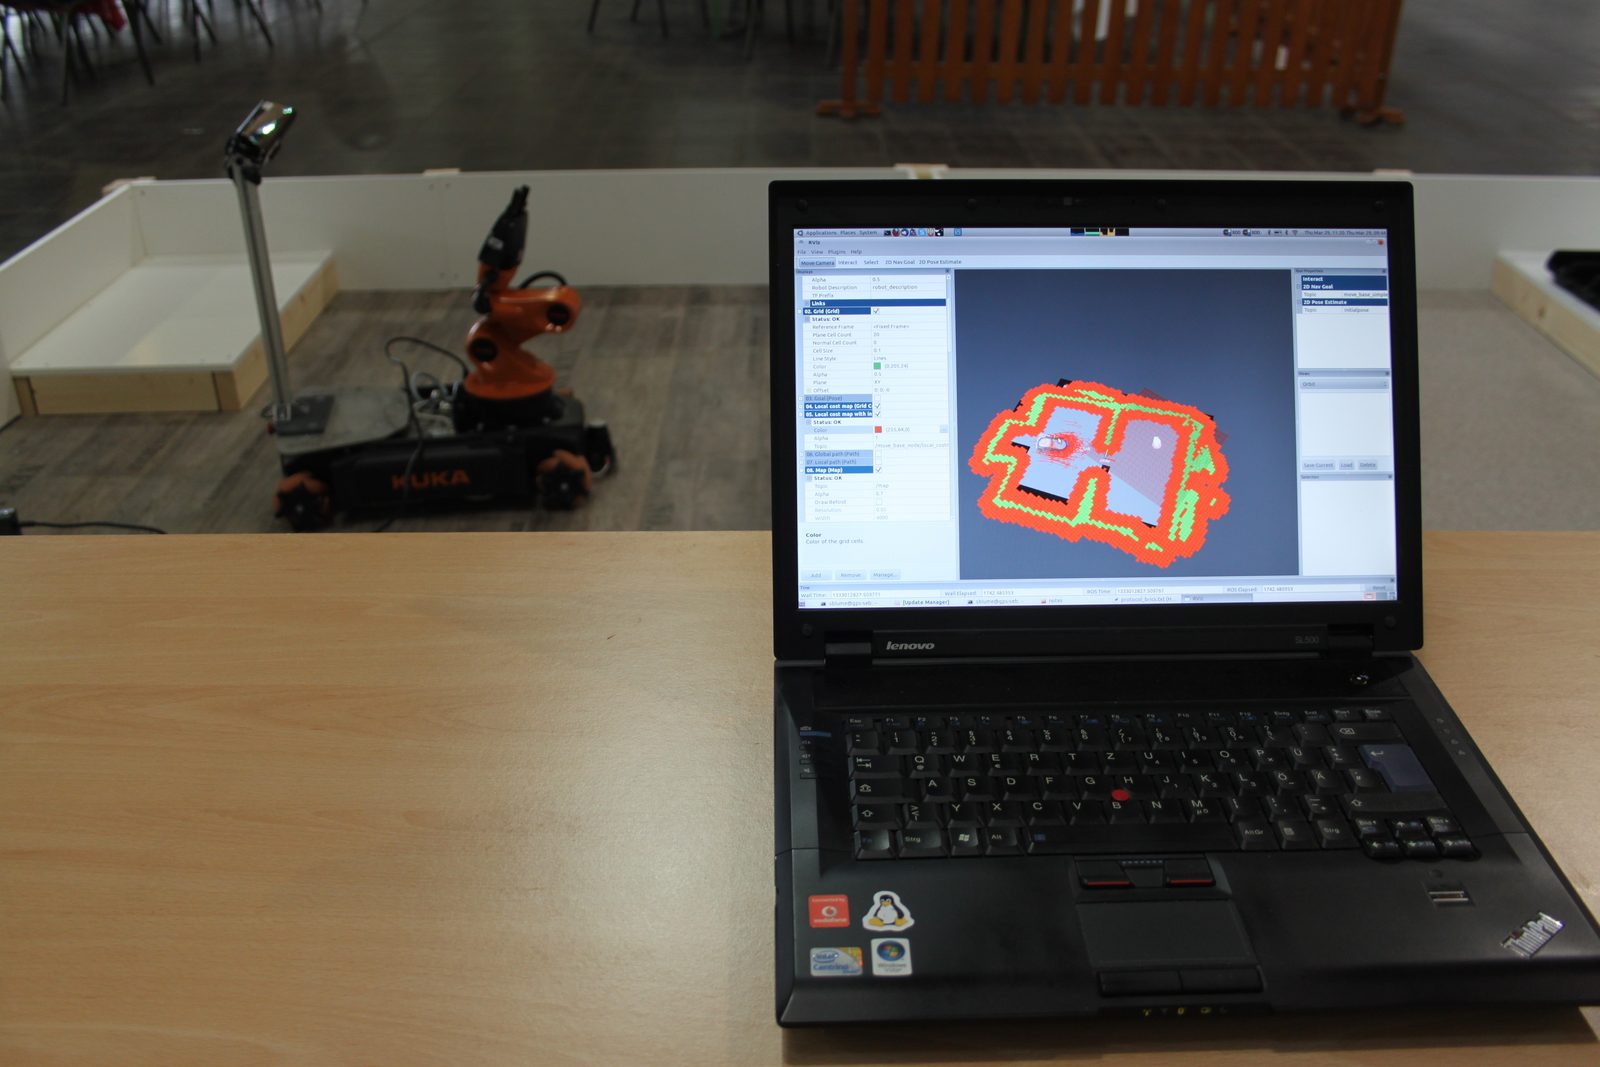
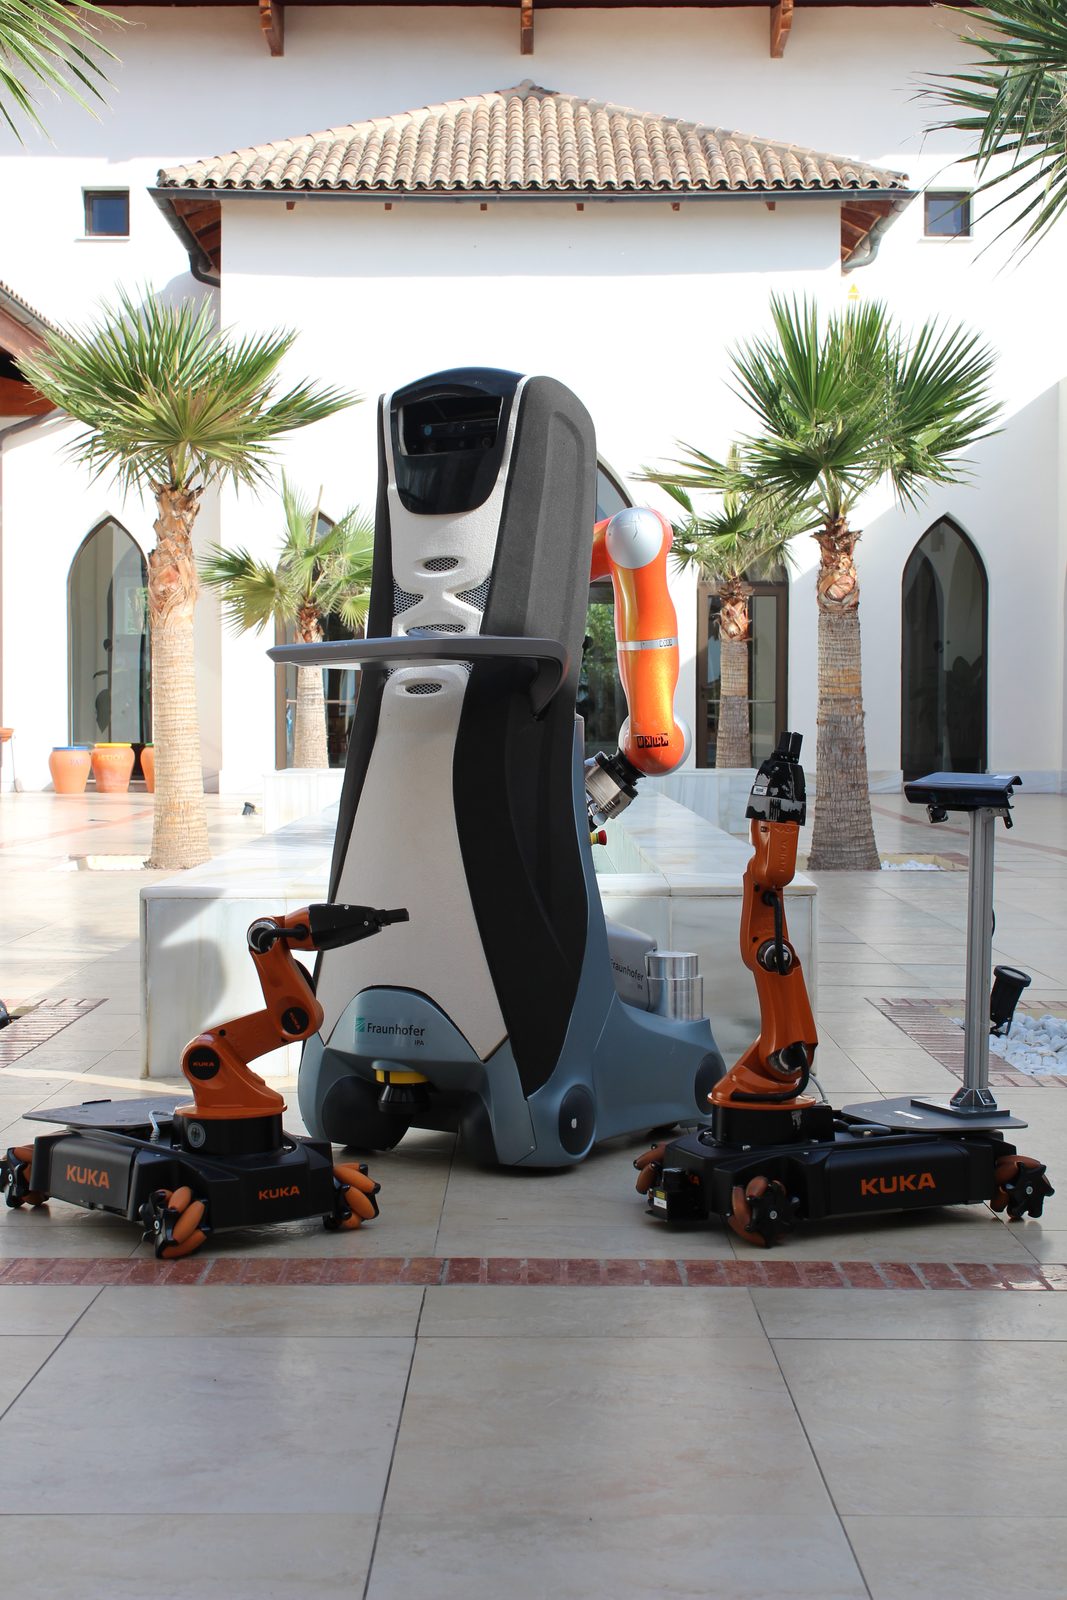
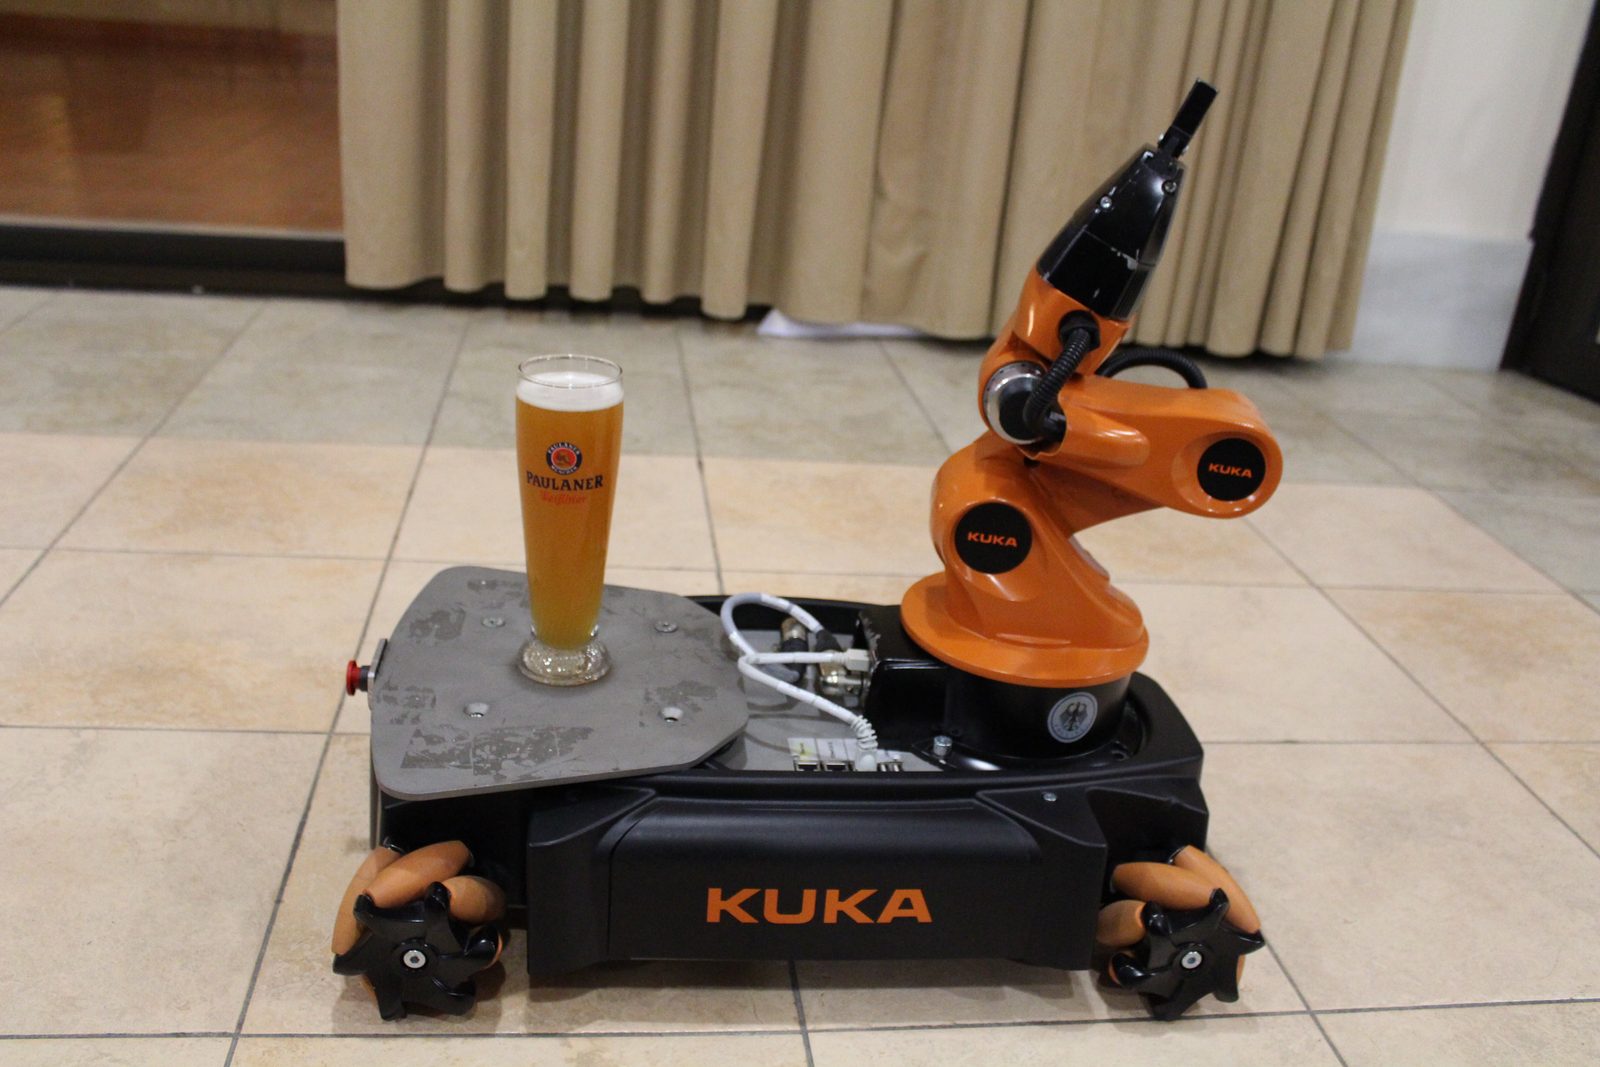
The KUKA youBot is an educational and research robot for mobile manipulation. In my role at Locomotec, I contributed to the open-source SDK and sensor ecosystem.
During a fair a person approached me: "I know your name from the author list of the ROS wrapper for the youBot driver." One of the pros of open-source software is getting recognized :)
Tech: ROS